CN111480547A - A device suitable for automatic tree planting in multiple terrains - Google Patents
A device suitable for automatic tree planting in multiple terrains Download PDFInfo
- Publication number
- CN111480547A CN111480547A CN202010438861.3A CN202010438861A CN111480547A CN 111480547 A CN111480547 A CN 111480547A CN 202010438861 A CN202010438861 A CN 202010438861A CN 111480547 A CN111480547 A CN 111480547A
- Authority
- CN
- China
- Prior art keywords
- tree
- frame
- tree planting
- sapling
- planting
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images

Classifications
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01G—HORTICULTURE; CULTIVATION OF VEGETABLES, FLOWERS, RICE, FRUIT, VINES, HOPS OR SEAWEED; FORESTRY; WATERING
- A01G23/00—Forestry
- A01G23/02—Transplanting, uprooting, felling or delimbing trees
- A01G23/04—Transplanting trees; Devices for grasping the root ball, e.g. stump forceps; Wrappings or packages for transporting trees
- A01G23/043—Transplanting devices for grasping, undercutting or transporting the root ball
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01C—PLANTING; SOWING; FERTILISING
- A01C11/00—Transplanting machines
- A01C11/02—Transplanting machines for seedlings
- A01C11/025—Transplanting machines using seedling trays; Devices for removing the seedlings from the trays
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01G—HORTICULTURE; CULTIVATION OF VEGETABLES, FLOWERS, RICE, FRUIT, VINES, HOPS OR SEAWEED; FORESTRY; WATERING
- A01G23/00—Forestry
- A01G23/02—Transplanting, uprooting, felling or delimbing trees
- A01G23/099—Auxiliary devices, e.g. felling wedges
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01C—PLANTING; SOWING; FERTILISING
- A01C5/00—Making or covering furrows or holes for sowing, planting or manuring
- A01C5/04—Machines for making or covering holes for sowing or planting
Landscapes
- Life Sciences & Earth Sciences (AREA)
- Environmental Sciences (AREA)
- Soil Sciences (AREA)
- Biodiversity & Conservation Biology (AREA)
- Ecology (AREA)
- Forests & Forestry (AREA)
- Transplanting Machines (AREA)
Abstract
Description
技术领域technical field
本发明涉及植树装置技术领域,尤其涉及一种可适用于多地形自动植树的装置。The invention relates to the technical field of tree planting devices, in particular to a device suitable for automatic tree planting in multiple terrains.
背景技术Background technique
20世纪以来随着世界人口数量急剧增长以及人类各种不合理的垦荒活动,造成了日益严重的全球荒漠化。荒漠化造成了严重的社会和环境问题,包括可耕地减少、沙尘暴频繁、土地整体涵养水源能力下降导致年降水量逐年减少等,严重恶化了人类的生存环境。因此,面对日益严峻的环境问题,大量植树造林将是有效遏制荒漠化的有效方法。植树是一项百年大计,对于环境的改善和人类长期可持续发展具有重大意义,目前植树工作主要依靠人工完成,费时费力,且工作效率较低,因此使用自动化机械设备来完成植树工作,将在很大程度上提高植树的工作效率,传统的纯手工植树操作一般由人采用铁锹、铁铲进行挖树坑,然后人工放入树苗,一人扶树一人覆土,最后适当压实后进行浇水即可。挖树坑和覆土过程非常的耗时费力,植树效率低、劳动强度大。为克服该缺陷,目前市场上出现了各种植树装置,例如植树机器人、植树机、植树挖掘机等。就如其中的中国发明专利公开了一种与挖掘机(挖沟机)配套使用的液压钻孔植树机,包括钻头和齿轮箱,在齿轮箱上有连接架,在齿轮箱上安装液压马达和减速机,液压马达经减速机带动齿轮箱中的齿轮,液压马达的输油管路连接挖掘机液压系统。该结构的种植机虽然由于采用的液压马达来对作为挖掘机构的钻头提供动力,动力足,可以对硬质土层、冻土地层等复杂土层进行挖掘工作。但其使用时,一方面需要配合与挖沟机进行使用,另一方面其只有自动化挖掘功能,对于植树过程的放树苗、培土操作无法在同一设备上完成,全自动化程度低。Since the 20th century, with the rapid growth of the world's population and various unreasonable land reclamation activities by human beings, the increasingly serious global desertification has been caused. Desertification has caused serious social and environmental problems, including the reduction of arable land, frequent sandstorms, and the decline of the overall water conservation capacity of the land, resulting in a decrease in annual precipitation, which has seriously deteriorated the living environment of human beings. Therefore, in the face of increasingly severe environmental problems, a large number of afforestation will be an effective method to effectively curb desertification. Tree planting is a century-old plan, which is of great significance to the improvement of the environment and the long-term sustainable development of human beings. At present, the tree planting work is mainly done manually, which is time-consuming and labor-intensive, and the work efficiency is low. To greatly improve the work efficiency of tree planting, in the traditional pure manual tree planting operation, people generally use shovels and shovels to dig tree pits, then manually put saplings, one person supports the tree and one person covers the soil, and finally watering can be done after proper compaction. . The process of digging tree pits and covering soil is very time-consuming and labor-intensive, and the tree-planting efficiency is low and labor-intensive. In order to overcome this defect, various tree-planting devices, such as tree-planting robots, tree-planting machines, and tree-planting excavators, have appeared on the market. For example, the Chinese invention patent among them discloses a hydraulic drilling and tree planting machine used in conjunction with an excavator (ditching machine), including a drill bit and a gear box, a connecting frame on the gear box, and a hydraulic motor and The reducer, the hydraulic motor drives the gears in the gearbox through the reducer, and the oil pipeline of the hydraulic motor is connected to the hydraulic system of the excavator. Although the planter of this structure uses a hydraulic motor to provide power to the drill bit as an excavation mechanism, the power is sufficient, and it can excavate complex soil layers such as hard soil layers and frozen soil layers. However, when it is used, on the one hand, it needs to be used in conjunction with the trencher, on the other hand, it only has the function of automatic excavation. The operation of placing saplings and cultivating soil in the tree planting process cannot be completed on the same equipment, and the degree of full automation is low.
如何解决上述现有技术中的问题,是本发明面临的课题。How to solve the above-mentioned problems in the prior art is the subject of the present invention.
发明内容SUMMARY OF THE INVENTION
本发明的目的在于提供一种自动化程度高、植树作业效率高、栽种质量高、传输精准、连续性好、树苗存活率高的适用于多地形自动植树的装置。The purpose of the present invention is to provide a device suitable for automatic tree planting in multiple terrains with high degree of automation, high tree planting operation efficiency, high planting quality, accurate transmission, good continuity and high sapling survival rate.
本发明是通过如下措施实现的:一种可适用于多地形自动植树的装置,其中,包括车架,设置所述车架底部的行走部件,设置在所述车架前端的挖土钻孔机构,设置在所述车架顶部的备苗部件,设置在所述车架上,控制所述备苗部件的备苗驱动组件,以及设置在所述车架后端,与所述备苗部件的输出端相配合的栽树组件。The present invention is realized by the following measures: a device suitable for automatic tree planting in multiple terrains, which includes a frame, a walking part at the bottom of the frame, and an excavation and drilling mechanism arranged at the front end of the frame , a seedling preparation part arranged on the top of the frame, a seedling preparation drive assembly arranged on the frame, and a seedling preparation drive assembly that controls the seedling preparation part; The tree planting component matched with the output end.
使用时,在备苗部件中准备待栽种树苗,行走部件带动车架行进过程中,位于车架前端的挖土钻孔机构在指定位置进行挖土钻孔形成树坑,行走部件继续带动车架行进,当栽树组件的作业位置与树坑处配合时,栽树组件将由备苗部件输出的树苗进行栽种,整个植树过程一气呵成,自动化程度高,设置行走部件,使装置可适用用于不同的地形使用。When in use, the saplings to be planted are prepared in the seedling preparation part. During the traveling process of driving the frame, the excavation and drilling mechanism at the front end of the frame digs and drills holes to form tree pits, and the walking part continues to drive the frame. Moving, when the working position of the tree-planting component is matched with the tree pit, the tree-planting component will plant the saplings output by the seedling preparation component. Terrain use.
本发明的具体特点还有,所述栽树组件包括两端贯通的落树筒,套接在所述落树筒外,且与所述落树筒的外侧面沿所述落树筒的中心线方向滑动配合的培土环,一端部铰接在所述车架上,另一端部铰接在所述培土环上的主液压杆,沿所述落树筒圆周方向均匀布置,一端部分别铰接在所述落树筒外圆周侧面上的若干个培土板,以及沿所述落树筒圆周方向均匀布置,一端分别铰接在所述培土环上,另一端分别铰接在相对应的所述培土板中部的若干个次液压杆。The specific feature of the present invention is that the tree-planting assembly includes a tree-falling barrel with two ends passing through, which is sleeved outside the tree-falling barrel, and is connected with the outer side of the tree-falling barrel along the center of the tree-falling barrel. The soil-cultivation ring slidingly matched in the line direction, one end is hinged on the frame, the other end is hinged on the main hydraulic rod on the soil-cultivation ring, and the main hydraulic rods are evenly arranged along the circumferential direction of the falling tree barrel, and one end is hinged on the Several soil-cultivation boards on the outer circumferential side of the tree-dropping tube, and uniformly arranged along the circumferential direction of the tree-falling tube, one end is respectively hinged on the said soil-cultivation ring, and the other end is hinged on the middle of the corresponding said soil-cultivation board respectively. Several secondary hydraulic rods.
使用时,当落树筒下端口正对树坑时,树苗穿过落树筒落下,主液压杆带动培土环上下运动,在次液压杆的带动下进行培土运动,培土板将树坑周围由挖土钻孔机构挖出来的土重新填回树坑中,完成栽树作业,作业效率高,且树苗不易倾倒,保证栽种质量,优选的,落树筒竖直设置,树苗落下的过程中亦呈直立形式,可以保证栽种的树苗直立整齐。When in use, when the lower port of the tree-dropping barrel is facing the tree pit, the saplings fall through the tree-falling barrel, the main hydraulic rod drives the soil-cultivation ring to move up and down, and the soil-cultivation movement is driven by the secondary hydraulic rod. The soil excavated by the soil drilling mechanism is refilled into the tree pit to complete the tree planting operation. The operation efficiency is high, and the saplings are not easy to fall to ensure the planting quality. The upright form ensures that the planted saplings are upright and neat.
本发明的具体特点还有,所述备苗部件包括固定在所述车架顶面上的传输槽,沿所述传输槽运动,均匀置于所述传输槽内的若干个树苗桶,以及驱动若干个所述树苗桶沿所述传输槽运动的传输驱动组件;The specific feature of the present invention is that the seedling preparation component includes a transmission groove fixed on the top surface of the frame, moves along the transmission groove, and evenly places a plurality of sapling buckets in the transmission groove, and drives the a plurality of transmission drive assemblies for moving the sapling buckets along the transmission trough;
所述落树筒正上方的所述传输槽底壁上开设与所述落树筒相配合的落树孔;A tree-fall hole matched with the tree-fall barrel is provided on the bottom wall of the transfer trough just above the tree-fall barrel;
所述树苗桶的底端开设与所述落权孔相配合的通孔,优选的,树苗桶的上下两端均通透,方便树苗坠落后及时补充树苗。The bottom end of the sapling bucket is provided with a through hole matched with the drop hole. Preferably, the upper and lower ends of the sapling bucket are transparent, so that the sapling can be replenished in time after the sapling falls.
使用时,在每一个树苗桶内各放置一个树根朝下的树苗,若干个树苗桶由传输驱动组件驱动沿传输槽运动,当落树筒下端口正对树坑时,其中一个树苗桶底端的通孔与落树孔对正,树苗在自身重力作用下,依次通过通孔、落树孔后,坠落至落树筒内,并继续由栽树组件完成栽树作业,由于树苗桶沿传输槽运动,且落树孔与落树筒相配合,可以保证备苗部件向栽树组件精准传输树苗,可根据需要设置树苗桶的通孔与落树孔对正的时间间隔,保证每一次栽树作业均有且仅有一个树苗配合作业。When in use, place a sapling with the root down in each sapling bucket, and several sapling buckets are driven by the transmission drive component to move along the transmission groove. The through hole and the falling tree hole are aligned. Under the action of its own gravity, the sapling passes through the through hole and the falling tree hole in sequence, and then falls into the tree falling tube, and continues to complete the tree planting operation by the tree planting component. Movement, and the coordination of the falling tree hole and the falling tree barrel can ensure that the seedling preparation component accurately transmits the saplings to the tree planting component, and the time interval between the through hole of the sapling barrel and the falling tree hole can be set as required to ensure that every tree is planted. There is one and only one sapling to cooperate with the job.
本发明的具体特点还有,所述传输槽的形状设置为跑道型,所述传输驱动组件包括沿跑道型的所述传输槽中部的侧壁首尾相接设置,且与所述传输槽滑动配合的内齿条环,以及设置在所述车架中部,与所述内齿条环相啮合的第一齿轮;若干个所述树苗桶分别与所述内齿条环相连接;所述第一齿轮的转轴与所述备苗驱动组件的输出轴同轴。The specific feature of the present invention is that the shape of the transmission tank is set as a racetrack type, and the transmission drive assembly comprises a side wall of the racetrack-shaped middle part of the transmission tank that is arranged end-to-end and is slidably matched with the transmission tank The inner rack ring of the vehicle frame, and a first gear arranged in the middle of the frame and meshing with the inner rack ring; a plurality of the sapling barrels are respectively connected with the inner rack ring; the first gear The rotating shaft of the gear is coaxial with the output shaft of the seedling preparation drive assembly.
通过第一齿轮的转动带动内齿条环沿跑道型的传输槽转动,进而带动树苗桶沿传输槽运动,传输精确,结构简单,运行平稳。The rotation of the first gear drives the inner rack ring to rotate along the racetrack-shaped transmission groove, and then drives the sapling barrel to move along the transmission groove. The transmission is accurate, the structure is simple, and the operation is stable.
本发明的具体特点还有,所述备苗驱动组件包括转轴与所述第一齿轮的转轴同轴的槽轮,与所述槽轮相配合的拨盘,固定在所述车架上的槽轮机架,以及设置在所述槽轮机架上,与输出轴与所述拨盘的转轴同轴的第一电机。The specific feature of the present invention is that the seedling preparation drive assembly includes a sheave with a rotating shaft coaxial with the rotating shaft of the first gear, a dial matched with the sheave, and a groove fixed on the frame. a wheel frame, and a first motor arranged on the sheave frame and coaxial with the output shaft and the rotating shaft of the dial.
设置由相互配合的拨盘、槽轮对传输驱动组件进行驱动,可以进一步确保树苗桶的精准传输,同时可以延长通孔与落树孔对正时树苗桶的停留时间,防止树苗坠落过程中树苗桶转动引起树苗被卡,影响植树的连贯性。The transmission and drive components are driven by the matched dials and sheaves, which can further ensure the accurate transmission of the sapling barrel, and at the same time can prolong the residence time of the sapling barrel when the through hole and the falling tree hole are aligned, preventing the sapling during the fall of the sapling. The rotation of the barrel causes the sapling to be stuck, affecting the continuity of the tree planting.
本发明的具体特点还有,所述备苗部件还包括在相邻两个所述树苗桶之间各设置一个连接筋,保证若干个树苗桶传输平稳且间距不变,进一步保证传输的精准性,优选的,所述连接筋的材质设置为弹性材料。The specific feature of the present invention is that the seedling preparation component further includes a connecting rib arranged between two adjacent sapling buckets to ensure smooth transmission of several sapling buckets with constant spacing, and further ensure the accuracy of transmission. , preferably, the material of the connecting rib is set to be an elastic material.
本发明的具体特点还有,所述挖土钻孔机构包括在所述车架上的固定机架,与所述固定机架沿竖直方向滑动配合的活动机架,固定在所述活动机架上的第二电机,设置在所述第二电机的输出轴上的钻头,所述钻头的外径与落树筒的内径相匹配,确保钻头挖的树坑与树苗配合,保证树苗顺利以竖直形式坠落至树坑底部,保证栽种效率及栽种质量,固定在所述车架上的第三电机,转轴与所述第三电机的输出轴同轴的第二齿轮,以及固定在所述活动机架上,与所述第二齿轮相啮合的齿条。The specific feature of the present invention is that the excavation and drilling mechanism includes a fixed frame on the frame, and a movable frame slidingly matched with the fixed frame in the vertical direction is fixed on the movable frame. The second motor on the frame, the drill bit arranged on the output shaft of the second motor, the outer diameter of the drill bit matches the inner diameter of the falling tree barrel, to ensure that the tree pit dug by the drill bit is matched with the sapling, and to ensure that the sapling goes smoothly. The vertical form falls to the bottom of the tree pit to ensure planting efficiency and planting quality, the third motor fixed on the frame, the second gear whose rotating shaft is coaxial with the output shaft of the third motor, and the second gear fixed on the On the movable frame, the rack meshes with the second gear.
优选的,所述钻头设置为绞龙式钻头,使用时,钻头随第二电机转动,第二齿轮随第三电机转动,与第二齿轮相啮合的齿条带动活动机架沿固定机架上下移动,即钻头在旋转的同时上下移动,进入土层进行旋土并将土带去,形成树坑,作业效率高,且未旋出的松动的土壤落入树坑底部,便于栽种的树苗进行扎根生长,提高树苗存活率,所述绞龙式钻头为现有技术,在此不再赘述。Preferably, the drill bit is set as an auger-type drill bit. When in use, the drill bit rotates with the second motor, the second gear rotates with the third motor, and the rack meshing with the second gear drives the movable frame up and down along the fixed frame Movement, that is, the drill bit moves up and down while rotating, enters the soil layer, spins the soil and takes the soil away to form a tree pit. The operation efficiency is high, and the loose soil that has not been rotated out falls into the bottom of the tree pit, which is convenient for the planted saplings to carry out. Rooting and growing, improving the survival rate of saplings, the auger-type drill bit is the prior art, which will not be repeated here.
本发明的具体特点还有,所述行走部件设置为履带式行走轮,优选的,所述履带式行走轮的履带设置为链式履带,便于在多种复杂地形使用。The specific feature of the present invention is further that the traveling member is set as a crawler-type traveling wheel, preferably, the crawler of the crawler-type traveling wheel is set as a chain crawler, which is convenient for use in various complex terrains.
本发明的有益效果为:本发明在车架上设置挖土钻孔机构、备苗部件及栽树组件,可以使整个植树过程一气呵成,自动化程度高,设置行走部件,使装置可适用用于不同的地形使用;设置落树筒,可以保证树苗根部朝下顺畅坠落,在落树筒外套设由主液压杆控制的培土环,由次液压杆与培土环带动的培土板,可以保证树苗落下后即随即进行培土作业,进一步提高载树作业效率,且树苗不易倾倒,保证栽种质量;设置备苗部件,可以方便控制两个树苗桶通过落树孔的时间间隔,保证每次有且仅有一个树苗从落树孔坠落,保证装置的连续性;设置由相互配合的拨盘、槽轮对传输驱动组件进行驱动,可以进一步确保树苗桶的精准传输,同时可以延长通孔与落树孔对正时树苗桶的停留时间,防止树苗坠落过程中树苗桶转动引起树苗被卡,影响植树的连贯性;设置连接筋,保证若干个树苗桶传输平稳且间距不变,进一步保证传输的精准性;设置可上下移动的钻头,使钻头进入土层进行旋土并将土带去,形成树坑,作业效率高,且未旋出的松动的土壤落入树坑底部,便于栽种的树苗进行扎根生长,提高树苗存活率。The beneficial effects of the present invention are as follows: the present invention is provided with an excavation and drilling mechanism, a seedling preparation component and a tree planting component on the frame, so that the entire tree planting process can be completed in one go, with a high degree of automation. Set up a tree-dropping tube to ensure that the roots of the saplings fall down smoothly. A soil-cultivating ring controlled by the main hydraulic rod is set on the outside of the tree-falling tube, and a soil-cultivating plate driven by the secondary hydraulic rod and the soil-cultivating ring can ensure that the saplings fall after falling. That is to say, the soil cultivation operation is carried out immediately, which further improves the efficiency of the tree-loading operation, and the saplings are not easily toppled to ensure the planting quality; the installation of seedling preparation components can easily control the time interval between the two sapling buckets passing through the tree-dropping holes, ensuring that there is only one sapling bucket at a time. The sapling falls from the tree hole to ensure the continuity of the device; the transmission drive components are driven by the matched dial and sheave, which can further ensure the accurate transmission of the sapling bucket, and can extend the alignment of the through hole and the tree hole. It can prevent the saplings from being stuck due to the rotation of the sapling bucket during the fall of the saplings, which will affect the continuity of the tree planting; set up connecting ribs to ensure that the transmission of several sapling buckets is stable and the spacing is unchanged, further ensuring the accuracy of transmission; setting The drill bit that can move up and down allows the drill bit to enter the soil layer to spin the soil and take the soil away to form a tree pit. The operation efficiency is high, and the unscrewed loose soil falls into the bottom of the tree pit, which is convenient for the planted saplings to take root and grow. Improve sapling survival rate.
附图说明Description of drawings
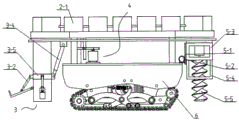
图1为本发明的结构示意图;Fig. 1 is the structural representation of the present invention;
图2为本发明的主视图;Fig. 2 is the front view of the present invention;
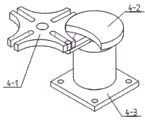
图3为本发明的局部结构示意图。FIG. 3 is a schematic diagram of a partial structure of the present invention.
其中,附图标记为: 1、车架;2、备苗部件;2-1、树苗桶;2-2、内齿条环;2-3、第一齿轮;2-4、传输槽;2-5、连接筋;3、栽树组件;3-1、落树筒;3-2、次液压杆;3-3、培土板;3-4、主液压杆;3-5、培土环;4、备苗驱动组件;4-1、槽轮、4-2、拨盘;4-3、槽轮机架;5、挖土钻孔机构;5-1、齿条;5-2、第二齿轮;5-3、活动机架;5-4、固定机架;5-5、钻头;6、履带式行走轮。Wherein, the reference signs are: 1. Frame; 2. Seedling preparation parts; 2-1, Sapling bucket; 2-2, Internal rack ring; 2-3, First gear; 2-4, Transmission groove; 2 -5, connecting bars; 3, tree planting components; 3-1, falling tree tube; 3-2, secondary hydraulic rod; 3-3, soil cultivation plate; 3-4, main hydraulic rod; 3-5, soil cultivation ring; 4. Seedling preparation drive assembly; 4-1, Sheave, 4-2, Dial; 4-3, Sheave frame; 5. Excavation and drilling mechanism; 5-1, Rack; 5-2, No. Two gears; 5-3, movable frame; 5-4, fixed frame; 5-5, drill bit; 6, crawler walking wheel.
具体实施方式Detailed ways
为能清楚说明本方案的技术特点,下面通过具体实施方式,对本方案进行阐述。In order to clearly illustrate the technical features of the solution, the solution will be described below through specific implementations.
参见图1至图3,本发明是:一种可适用于多地形自动植树的装置,其中,包括车架1,设置车架1底部的行走部件,设置在车架1前端的挖土钻孔机构5,设置在车架1顶部的备苗部件2,设置在车架1上,控制备苗部件2的备苗驱动组件4,以及设置在车架1后端,与备苗部件2的输出端相配合的栽树组件3。Referring to FIGS. 1 to 3 , the present invention is a device suitable for automatic tree planting in multiple terrains, including a vehicle frame 1 , a walking part at the bottom of the vehicle frame 1 , and an excavation hole arranged at the front end of the vehicle frame 1
使用时,在备苗部件2中准备待栽种树苗,行走部件带动车架1行进过程中,位于车架1前端的挖土钻孔机构5在指定位置进行挖土钻孔形成树坑,行走部件继续带动车架1行进,当栽树组件3的作业位置与树坑处配合时,栽树组件3将由备苗部件2输出的树苗进行栽种,整个植树过程一气呵成,自动化程度高,设置行走部件,使装置可适用用于不同的地形使用。When in use, the saplings to be planted are prepared in the
本发明的具体特点还有,栽树组件3包括两端贯通的落树筒3-1,套接在落树筒3-1外,且与落树筒3-1的外侧面沿落树筒3-1的中心线方向滑动配合的培土环3-5,一端部铰接在车架1上,另一端部铰接在培土环3-5上的主液压杆3-4,沿落树筒3-1圆周方向均匀布置,一端部分别铰接在落树筒3-1外圆周侧面上的若干个培土板3-3,以及沿落树筒3-1圆周方向均匀布置,一端分别铰接在培土环3-5上,另一端分别铰接在相对应的培土板3-3中部的若干个次液压杆3-2。The specific feature of the present invention is that the tree planting assembly 3 includes a tree trunk 3-1 with two ends passing through, which is sleeved outside the tree trunk 3-1, and is connected with the outer side of the tree trunk 3-1 along the tree trunk. The soil-cultivation ring 3-5 slidingly fitted in the direction of the centerline of 3-1, one end is hinged on the frame 1, and the other end is hinged on the main hydraulic rod 3-4 on the soil-cultivation ring 3-5, along the tree-dropping tube 3- 1. A plurality of soil cultivating plates 3-3 are evenly arranged in the circumferential direction, one end of which is respectively hinged on the outer circumferential side of the tree-dropping tube 3-1, and are evenly arranged along the circumferential direction of the tree-dropping tube 3-1, and one end is hinged on the soil-cultivating ring 3 respectively. -5, the other ends are respectively hinged to a number of secondary hydraulic rods 3-2 in the middle of the corresponding cultivating plate 3-3.
使用时,当落树筒3-1下端口正对树坑时,树苗穿过落树筒3-1落下,主液压杆3-4带动培土环3-5上下运动,在次液压杆3-4的带动下进行培土运动,培土板3-3将树坑周围由挖土钻孔机构5挖出来的土重新填回树坑中,完成栽树作业。When in use, when the lower port of the tree-dropping tube 3-1 is facing the tree pit, the saplings fall through the tree-dropping tube 3-1, and the main hydraulic rod 3-4 drives the earth-cultivating ring 3-5 to move up and down. The soil-cultivation movement is carried out under the driving of the cultivator, and the soil-cultivation plate 3-3 refills the soil dug out by the soil excavation and
本发明的具体特点还有,备苗部件2包括固定在车架1顶面上的传输槽2-4,沿传输槽2-4运动,均匀置于传输槽2-4内的若干个树苗桶2-1,以及驱动若干个树苗桶2-1沿传输槽2-4运动的传输驱动组件;The specific feature of the present invention is that the
落树筒3-1正上方的传输槽2-4底壁上开设与落树筒3-1相配合的落树孔;The bottom wall of the transmission groove 2-4 directly above the tree-falling barrel 3-1 is provided with a tree-falling hole matched with the tree-falling barrel 3-1;
树苗桶2-1的底端开设与落权孔相配合的通孔。The bottom end of the sapling bucket 2-1 is provided with a through hole matched with the drop hole.
使用时,在每一个树苗桶2-1内各放置一个树根朝下的树苗,若干个树苗桶2-1由传输驱动组件驱动沿传输槽2-4运动,当落树筒3-1下端口正对树坑时,其中一个树苗桶2-1底端的通孔与落树孔对正,树苗在自身重力作用下,依次通过通孔、落树孔后,坠落至落树筒3-1内,并继续由栽树组件3完成栽树作业,由于树苗桶2-1沿传输槽2-4运动,且落树孔与落树筒3-1相配合,可以备苗部件2向栽树组件3精准传输树苗,可根据需要设置树苗桶2-1的通孔与落树孔对正的时间间隔,保证每一次栽树作业均有且仅有一个树苗配合作业。When in use, place a sapling with the roots down in each sapling bucket 2-1, and several sapling buckets 2-1 are driven by the transmission drive assembly to move along the transmission groove 2-4. When facing the tree pit, the through hole at the bottom of one of the sapling buckets 2-1 is aligned with the falling tree hole. Under the action of its own gravity, the sapling will pass through the through hole and the falling tree hole in turn, and then fall into the falling tree barrel 3-1. , and continue to complete the tree planting operation by the tree planting assembly 3. Since the sapling barrel 2-1 moves along the transfer groove 2-4, and the tree falling hole is matched with the tree falling barrel 3-1, the
本发明的具体特点还有,传输槽2-4的形状设置为跑道型,传输驱动组件包括沿跑道型的传输槽2-4中部的侧壁首尾相接设置,且与传输槽2-4滑动配合的内齿条环2-2,以及设置在车架1中部,与内齿条环2-2相啮合的第一齿轮2-3;若干个树苗桶2-1分别与内齿条环2-2相连接;第一齿轮2-3的转轴与备苗驱动组件4的输出轴同轴。The specific feature of the present invention is that the shape of the transmission groove 2-4 is set as a racetrack type, and the transmission drive assembly comprises a side wall in the middle of the racetrack-shaped transmission groove 2-4 that is arranged end to end, and slides with the transmission groove 2-4. The matching inner rack ring 2-2, and the first gear 2-3 arranged in the middle of the frame 1 and meshing with the inner rack ring 2-2; several sapling barrels 2-1 are respectively connected with the inner rack ring 2 -2 is connected; the rotating shaft of the first gear 2-3 is coaxial with the output shaft of the seedling preparation drive assembly 4 .
通过第一齿轮2-3的转动带动内齿条环2-2沿跑道型的传输槽2-4转动,进而带动树苗桶2-1沿传输槽2-4运动,传输精确,结构简单,运行平稳。Through the rotation of the first gear 2-3, the inner rack ring 2-2 is driven to rotate along the racetrack-shaped transmission groove 2-4, thereby driving the sapling bucket 2-1 to move along the transmission groove 2-4. The transmission is accurate, the structure is simple, and the operation is smooth.
本发明的具体特点还有,备苗驱动组件4包括转轴与第一齿轮2-3的转轴同轴的槽轮4-1,与槽轮4-1相配合的拨盘4-2,固定在车架1上的槽轮机架4-3,以及设置在槽轮机架4-3上,与输出轴与拨盘4-2的转轴同轴的第一电机。The specific feature of the present invention is that the seedling preparation drive assembly 4 includes a sheave 4-1 whose rotating shaft is coaxial with the rotating shaft of the first gear 2-3, and a dial 4-2 matched with the sheave 4-1, which is fixed on the The sheave frame 4-3 on the vehicle frame 1, and the first motor arranged on the sheave frame 4-3 and coaxial with the output shaft and the rotating shaft of the dial 4-2.
设置由相互配合的拨盘4-2、槽轮4-1对传输驱动组件进行驱动,可以进一步确保树苗桶2-1的精准传输,同时可以延长通孔与落树孔对正时树苗桶2-1的停留时间,防止树苗坠落过程中树苗桶2-1转动引起树苗被卡,影响植树的连贯性。The transmission drive assembly is driven by the matched dial 4-2 and the sheave 4-1, which can further ensure the accurate transmission of the sapling bucket 2-1, and can extend the alignment of the through hole and the falling tree hole when the
本发明的具体特点还有,备苗部件2还包括在相邻两个树苗桶2-1之间各设置一个连接筋2-5,保证若干个树苗桶2-1传输平稳且间距不变,进一步保证传输的精准性,优选的,连接筋2-5的材质设置为弹性材料。The specific feature of the present invention is that the
本发明的具体特点还有,挖土钻孔机构5包括在车架1上的固定机架5-4,与固定机架5-4沿竖直方向滑动配合的活动机架5-3,固定在活动机架5-3上的第二电机,设置在第二电机的输出轴上的钻头5-5,固定在车架1上的第三电机,转轴与第三电机的输出轴同轴的第二齿轮5-2,以及固定在活动机架5-3上,与第二齿轮5-2相啮合的齿条5-1。The specific feature of the present invention is that the excavation and
优选的,钻头5-5设置为绞龙式钻头,使用时,钻头5-5随第二电机转动,第二齿轮5-2随第三电机转动,与第二齿轮5-2相啮合的齿条5-1带动活动机架5-3沿固定机架5-4上下移动,即钻头5-5在旋转的同时上下移动,进入土层进行旋土并将土带去,形成树坑,绞龙式钻头为现有技术,在此不再赘述。Preferably, the drill bit 5-5 is configured as an auger-type drill bit. When in use, the drill bit 5-5 rotates with the second motor, the second gear 5-2 rotates with the third motor, and the teeth meshing with the second gear 5-2 The strip 5-1 drives the movable frame 5-3 to move up and down along the fixed frame 5-4, that is, the drill bit 5-5 moves up and down while rotating, enters the soil layer to spin the soil and take the soil away to form a tree pit and twist the soil. The dragon-type drill bit is in the prior art and will not be repeated here.
本发明的具体特点还有,行走部件设置为履带式行走轮6,优选的,履带式行走轮6的履带设置为链式履带,便于在多种复杂地形使用。The specific features of the present invention are further that the traveling parts are set as crawler-type traveling wheels 6, and preferably, the crawler belts of the crawler-type traveling wheels 6 are set as chain-type crawler tracks, which is convenient for use in various complex terrains.
本发明未经描述的技术特征可以通过或采用现有技术实现,在此不再赘述,当然,上述说明并非是对本发明的限制,本发明也并不仅限于上述举例,本技术领域的普通技术人员在本发明的实质范围内所做出的变化、改型、添加或替换,也应属于本发明的保护范围。The undescribed technical features of the present invention can be realized by or using the existing technology, and will not be repeated here. Of course, the above description is not a limitation of the present invention, and the present invention is not limited to the above examples. Those skilled in the art Changes, modifications, additions or substitutions made within the essential scope of the present invention shall also belong to the protection scope of the present invention.
Claims (8)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010438861.3A CN111480547B (en) | 2020-05-22 | 2020-05-22 | Device suitable for automatically planting trees on multiple terrains |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010438861.3A CN111480547B (en) | 2020-05-22 | 2020-05-22 | Device suitable for automatically planting trees on multiple terrains |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN111480547A true CN111480547A (en) | 2020-08-04 |
| CN111480547B CN111480547B (en) | 2022-02-08 |
Family
ID=71795412
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202010438861.3A Active CN111480547B (en) | 2020-05-22 | 2020-05-22 | Device suitable for automatically planting trees on multiple terrains |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN111480547B (en) |
Cited By (14)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112056171A (en) * | 2020-09-21 | 2020-12-11 | 刘昶 | Garden seedling planting method |
| CN112586305A (en) * | 2021-01-18 | 2021-04-02 | 辽宁科技大学 | Full-automatic tree planting robot |
| CN114009303A (en) * | 2021-11-18 | 2022-02-08 | 武汉大学 | Full-automatic tree planting vehicle |
| CN114375759A (en) * | 2021-12-13 | 2022-04-22 | 六安市叶集区绿叶果木种植专业合作社 | Grape trellis with prevent wind effect and erection equipment thereof |
| CN114568244A (en) * | 2022-03-10 | 2022-06-03 | 武夷学院 | Tree planting vehicle suitable for multiple terrains and use method |
| CN114586635A (en) * | 2022-03-11 | 2022-06-07 | 李思哲 | An integrated tree planting robot |
| CN114616951A (en) * | 2022-03-25 | 2022-06-14 | 北京理工大学珠海学院 | Automatic planting mechanism and control method thereof |
| CN114830989A (en) * | 2022-06-13 | 2022-08-02 | 哈尔滨剑桥学院 | Full-automatic desert tree planting vehicle |
| CN114982583A (en) * | 2022-06-17 | 2022-09-02 | 重庆交通大学 | Excavation and cultivation integrated tree planting robot |
| CN114982674A (en) * | 2022-05-21 | 2022-09-02 | 四川航天职业技术学院(四川航天高级技工学校) | A kind of automatic coral planting device and coral planting method |
| CN115024183A (en) * | 2022-07-19 | 2022-09-09 | 淮南师范学院 | Desert tree planting robot |
| CN115250862A (en) * | 2022-07-27 | 2022-11-01 | 上海新园林实业有限公司 | Heavy metal polluted land reclamation restoration device and method |
| CN115316216A (en) * | 2022-08-30 | 2022-11-11 | 武汉工程大学 | Multi-sapling automatic planting robot |
| CN117617079A (en) * | 2023-03-17 | 2024-03-01 | 武夷学院 | Full-automatic haloxylon ammodendron tree planter |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP4627901A1 (en) * | 2024-03-28 | 2025-10-08 | Reil & Eichinger GmbH | Mobile planter and method for regular planting of plants |
Citations (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| ES256982U (en) * | 1981-03-18 | 1981-07-01 | Romeo Valero Ramon | Treadmilling machine, nursery and similar (Machine-translation by Google Translate, not legally binding) |
| CN104855016A (en) * | 2015-05-19 | 2015-08-26 | 潍坊友容实业有限公司 | Fixed-distance cultivating machine for saline-alkali soil |
| CN105340437A (en) * | 2015-11-23 | 2016-02-24 | 云南烟草机械有限责任公司 | Electric rotating digging self-propelled tobacco seedling transplanter |
| CN106664911A (en) * | 2016-12-13 | 2017-05-17 | 重庆市神女药业股份有限公司 | Traditional Chinese medicine seedling transplanter |
| CN107114207A (en) * | 2017-06-19 | 2017-09-01 | 韩登银 | A kind of gardens Tree planting vehicle |
| CN108575658A (en) * | 2018-05-30 | 2018-09-28 | 马鞍山松鹤信息科技有限公司 | A kind of excavator that can plant tree automatically |
| CN108739219A (en) * | 2018-04-28 | 2018-11-06 | 淮阴工学院 | Planting machine |
| CN110226486A (en) * | 2019-07-29 | 2019-09-13 | 高越 | Intelligent distant control Tree planting vehicle |
| CN212464338U (en) * | 2020-05-22 | 2021-02-05 | 中建八局第一建设有限公司 | Device suitable for automatically planting trees on multiple terrains |
-
2020
- 2020-05-22 CN CN202010438861.3A patent/CN111480547B/en active Active
Patent Citations (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| ES256982U (en) * | 1981-03-18 | 1981-07-01 | Romeo Valero Ramon | Treadmilling machine, nursery and similar (Machine-translation by Google Translate, not legally binding) |
| CN104855016A (en) * | 2015-05-19 | 2015-08-26 | 潍坊友容实业有限公司 | Fixed-distance cultivating machine for saline-alkali soil |
| CN105340437A (en) * | 2015-11-23 | 2016-02-24 | 云南烟草机械有限责任公司 | Electric rotating digging self-propelled tobacco seedling transplanter |
| CN106664911A (en) * | 2016-12-13 | 2017-05-17 | 重庆市神女药业股份有限公司 | Traditional Chinese medicine seedling transplanter |
| CN107114207A (en) * | 2017-06-19 | 2017-09-01 | 韩登银 | A kind of gardens Tree planting vehicle |
| CN108739219A (en) * | 2018-04-28 | 2018-11-06 | 淮阴工学院 | Planting machine |
| CN108575658A (en) * | 2018-05-30 | 2018-09-28 | 马鞍山松鹤信息科技有限公司 | A kind of excavator that can plant tree automatically |
| CN110226486A (en) * | 2019-07-29 | 2019-09-13 | 高越 | Intelligent distant control Tree planting vehicle |
| CN212464338U (en) * | 2020-05-22 | 2021-02-05 | 中建八局第一建设有限公司 | Device suitable for automatically planting trees on multiple terrains |
Non-Patent Citations (1)
| Title |
|---|
| 琬山等: "《机械制造手册》", 31 March 2003, 辽宁科学技术出版社 * |
Cited By (20)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112056171A (en) * | 2020-09-21 | 2020-12-11 | 刘昶 | Garden seedling planting method |
| CN112056171B (en) * | 2020-09-21 | 2021-12-07 | 淮北悯农生物科技有限公司 | Garden seedling planting method |
| CN112586305A (en) * | 2021-01-18 | 2021-04-02 | 辽宁科技大学 | Full-automatic tree planting robot |
| CN114009303A (en) * | 2021-11-18 | 2022-02-08 | 武汉大学 | Full-automatic tree planting vehicle |
| CN114009303B (en) * | 2021-11-18 | 2022-11-01 | 武汉大学 | Full-automatic tree planting vehicle |
| CN114375759A (en) * | 2021-12-13 | 2022-04-22 | 六安市叶集区绿叶果木种植专业合作社 | Grape trellis with prevent wind effect and erection equipment thereof |
| CN114375759B (en) * | 2021-12-13 | 2023-10-24 | 六安市叶集区绿叶果木种植专业合作社 | Grape trellis with prevent wind effect |
| CN114568244A (en) * | 2022-03-10 | 2022-06-03 | 武夷学院 | Tree planting vehicle suitable for multiple terrains and use method |
| CN114586635A (en) * | 2022-03-11 | 2022-06-07 | 李思哲 | An integrated tree planting robot |
| CN114616951A (en) * | 2022-03-25 | 2022-06-14 | 北京理工大学珠海学院 | Automatic planting mechanism and control method thereof |
| CN114982674A (en) * | 2022-05-21 | 2022-09-02 | 四川航天职业技术学院(四川航天高级技工学校) | A kind of automatic coral planting device and coral planting method |
| WO2023226890A1 (en) * | 2022-05-21 | 2023-11-30 | 四川航天职业技术学院(四川航天高级技工学校) | Automatic coral planting apparatus and coral planting method |
| CN114830989A (en) * | 2022-06-13 | 2022-08-02 | 哈尔滨剑桥学院 | Full-automatic desert tree planting vehicle |
| CN114982583A (en) * | 2022-06-17 | 2022-09-02 | 重庆交通大学 | Excavation and cultivation integrated tree planting robot |
| CN115024183A (en) * | 2022-07-19 | 2022-09-09 | 淮南师范学院 | Desert tree planting robot |
| CN115250862A (en) * | 2022-07-27 | 2022-11-01 | 上海新园林实业有限公司 | Heavy metal polluted land reclamation restoration device and method |
| CN115250862B (en) * | 2022-07-27 | 2023-08-01 | 上海新园林实业有限公司 | Heavy metal polluted land reclamation restoration device and method |
| CN115316216A (en) * | 2022-08-30 | 2022-11-11 | 武汉工程大学 | Multi-sapling automatic planting robot |
| CN115316216B (en) * | 2022-08-30 | 2023-12-29 | 武汉工程大学 | Multi-sapling automatic planting robot |
| CN117617079A (en) * | 2023-03-17 | 2024-03-01 | 武夷学院 | Full-automatic haloxylon ammodendron tree planter |
Also Published As
| Publication number | Publication date |
|---|---|
| CN111480547B (en) | 2022-02-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111480547B (en) | Device suitable for automatically planting trees on multiple terrains | |
| CN108029284B (en) | Fully automatic tree planting robot suitable for single row planting | |
| CN207869642U (en) | Full-automatic Machine for planting tree people suitable for uniline plantation | |
| CN105379475B (en) | Ginseng seedling transplanting earth boring machine | |
| CN217470714U (en) | Digging and backfilling integrated desert tree planting device | |
| CN114830989A (en) | Full-automatic desert tree planting vehicle | |
| CN107896590A (en) | The device of longitudinal transplanting rape pot seedling in a kind of groove | |
| CN221306481U (en) | Pit digging device for landscaping | |
| CN219612712U (en) | A vehicle suitable for planting apple tree seedlings in loess hilly landforms | |
| CN212464338U (en) | Device suitable for automatically planting trees on multiple terrains | |
| CN101702971A (en) | Tobacco seeds transplanter | |
| CN115024183A (en) | Desert tree planting robot | |
| CN119256696A (en) | A multifunctional barren slope repair machine | |
| CN218868914U (en) | Traction type composite sand barrier embedding machine | |
| CN207626073U (en) | The device of longitudinal transplanting rape pot seedling in a kind of groove | |
| CN218789539U (en) | A fully automatic salix planter | |
| CN202181567U (en) | Elevating type trenching apparatus | |
| CN114391337B (en) | A kind of digging and filling device for sweet potato planting | |
| CN118451812A (en) | Gardens fertilizer injection unit of quick fertilization | |
| CN210959372U (en) | A kind of Cistanche sowing equipment | |
| CN220570958U (en) | Greening planting equipment for environmental construction | |
| CN202750460U (en) | Marching type rhizoma dioscoreae excavator | |
| CN205648402U (en) | Plant is transplanted and plants system of planting | |
| CN222073851U (en) | Municipal greening maintenance equipment | |
| CN113940172A (en) | An ecological device for soil and water conservation |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |