Disclosure of Invention
The invention aims to provide a numerical control automatic fastener press-mounting machine which can effectively solve the technical problems.
In order to achieve the purpose of the invention, the following technical scheme is adopted: a numerically controlled automated fastener press comprising: the rotary worktable comprises a base frame, a rotary worktable and a driving mechanism, wherein the base frame is fixedly connected with a driving assembly; the base frame is fixedly connected with a space moving assembly, and the space moving assembly is fixedly connected with a C-shaped rack; the rotary workbench is characterized in that a press-fitting power head is arranged above the rotary workbench, a pressure detection assembly is fixedly connected to the press-fitting power head, a lower die supporting assembly is arranged under the pressure detection assembly, and the press-fitting power head and the lower die supporting assembly are fixedly connected with a C-shaped frame.
Preferably, the lower mold support assembly comprises: the first cylinder and the bottom plate are fixedly connected with the C-shaped frame; the first cylinder telescopic rod is fixedly connected with a sliding block, and the bottom plate is provided with a dovetail groove for sliding the sliding block; a supporting block is arranged right above the sliding block, the bottom plate is provided with a T-shaped groove matched with the supporting block, and the supporting block is provided with a position blocking rib matched with the T-shaped groove; the supporting block is fixedly connected with four guide posts, and the guide posts penetrate through the bottom plate and extend to the outer side; the supporting block is fixedly connected with four reset components.
Preferably, the reset assembly comprises: the screw penetrates through the bottom plate and is in threaded connection with the supporting block; the gasket and the spring are sleeved on the screw rod, and the spring is arranged between the bottom plate and the gasket.
Preferably, the slider is provided with a first inclined surface, and the support block is provided with a second inclined surface matched with the first inclined surface.
Preferably, the space moving assembly comprises: a plurality of first guide rails fixedly connected with the base frame; the first guide rail is provided with a movable plate in a sliding manner, the movable plate is driven by a first driving motor, and the first driving motor is fixedly connected with the base frame; the movable plate is fixedly connected with a plurality of second guide rails; the C-shaped frame moves along the length direction of the second guide rail; the C-shaped frame is driven by a second driving motor; and the second driving motor is fixedly connected with the moving plate.
Preferably, the drive assembly comprises: a cam indexer and a motor; the cam indexer is fixedly connected with the base frame; the motor drives the cam indexer to rotate, and the cam indexer drives the rotary workbench to rotate.
Preferably, the pressure detection assembly comprises: one end of the fixed block is fixedly connected with the press-fitting power head; the other end of fixed block is connected with a locating piece, the locating piece all is equipped with the cooperation space of mutual intercommunication with the fixed block, be equipped with a sensor and punching press head in the cooperation space, the punching press head passes the locating piece and extends to the outside.
Preferably, the rotary table comprises: the device comprises a disc, a plurality of station tables arranged on the disc, a positioning column used for placing a workpiece and a plurality of second cylinders used for driving the workpiece to move upwards, wherein a pneumatic slip ring is fixed at the axis of the disc.
Compared with the prior art, the invention has the following beneficial effects:
1. through drive assembly and disc cooperation, realize that the work piece transports to the station automatically, improve production efficiency. The space moving assembly is matched with the C-shaped frame to realize automatic riveting. Through drive assembly and swivel work head cooperation, the preinstallation of work piece moves with the pressure equipment simultaneously, mutually noninterfere to reduce artifical burden, improve production efficiency, reduced labour cost.
2. The pressure detection assembly does not need to rely on a hydraulic regulating valve or an air pressure regulating valve to regulate output pressure, and standard press-fitting force required by a fastener is flexibly adjusted under the condition of ensuring production efficiency. The phenomena of insufficient torque and push-pull force of the pressed finished product and indentation on the surface of the finished product are avoided.
3. The lower die supporting component reduces the condition that the disc deforms when the pressure is too high in the pressure riveting process, and the service life of the press-mounting machine is prolonged.
Drawings
In order to more clearly illustrate the technical solutions in the embodiments of the present invention, the drawings used in the description of the embodiments are briefly introduced below.
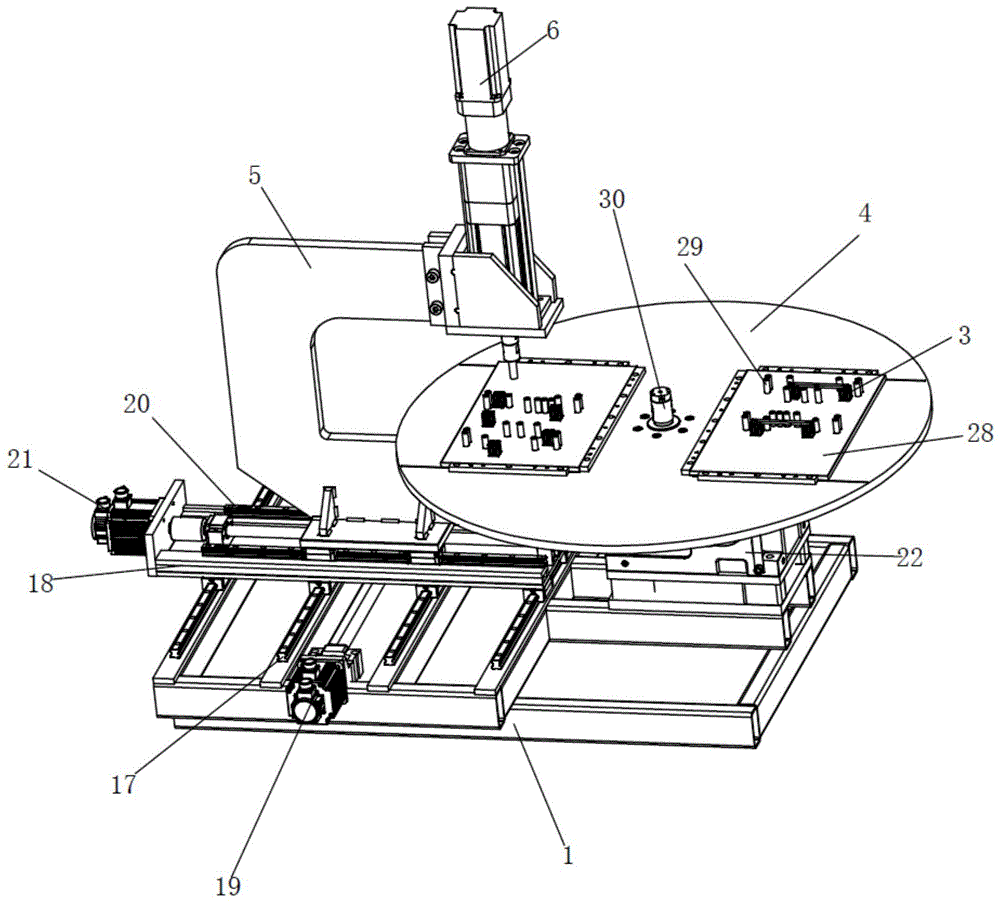
FIG. 1 is a schematic view of the overall structure of a numerical control automatic fastener press-fitting machine according to an embodiment of the invention;
FIG. 2 is a partial schematic view of a numerically controlled automated fastener press in an embodiment of the invention;
FIG. 3 is a partial cross-sectional view of a numerically controlled automated fastener press in an embodiment of the present invention;
FIG. 4 is a schematic structural view of a lower die supporting assembly of the numerical control automatic fastener press-fitting machine in the embodiment of the invention;
FIG. 5 is a partial enlarged view of a portion A of the numerically controlled automated fastener press in an embodiment of the present invention;
FIG. 6 is an enlarged view of a portion of a numerically controlled automated fastener press B in accordance with an embodiment of the present invention.
Description of the figures
1. The device comprises a base frame 2, a first air cylinder 3, a second air cylinder 4, a disc 5, a C-shaped frame 6, a servo electric cylinder 7, a bottom plate 8, a sliding block 9, a dovetail groove 10, a supporting block 11, a T-shaped groove 12, a blocking rib 13, a guide column 14, a screw rod 15, a spring 16, a gasket 17, a first guide rail 18, a moving plate 19, a first driving motor 20, a second guide rail 21, a second driving motor 22, a cam indexer 24, a fixed block 25, a positioning block 26, a sensor 27, a stamping head 28, a station table 29, a positioning column 30 and a pneumatic sliding ring.
Detailed Description
The technical solution of the present invention will be clearly and completely described below with reference to the accompanying drawings in the embodiments of the present invention.
As shown in fig. 1, a numerical control automatic fastener press-fitting machine includes: the base frame 1 is fixedly connected with a driving component, and the base frame 1 is fixedly connected with a driving component. The driving component is fixedly connected with a rotary worktable.
The drive assembly includes: a cam indexer 22 and a motor. The cam indexer 22 is fixedly connected with the base frame 1, and the motor drives the cam indexer 22 to rotate. The output shaft of the cam indexer 22 is fixedly connected with a rotary worktable, and the cam indexer 22 drives the rotary worktable to rotate.
The rotary table includes: the device comprises a disc 4, two station tables 28 arranged on the disc 4, a positioning column 29 used for placing a workpiece and four second cylinders 3 used for driving the workpiece to move upwards, wherein the difference between the two station tables 28 is 180 degrees.
The positioning column 29 and the four second cylinders 3 are all arranged on the station table 28. The four second cylinders 3 are divided into two groups, each group of second cylinders 3 is provided with a support frame, two ends of each support frame are fixedly connected with the telescopic rods of the second cylinders 3 respectively, a pneumatic sliding ring 30 is fixed at the axis of the disc 4, and a pressure source is provided for the second cylinders 3 after the workpieces are machined.
The cam indexer 22 is provided with two stations, the stations of the cam indexer 22 corresponding one-to-one to the station tables 28.
After the workpiece is riveted, the workpiece is difficult to take, the second cylinder 3 drives the support frame to move, and the support frame drives the workpiece to jack up, so that the workpiece can be conveniently taken after being formed.
The base frame 1 is fixedly connected with a space moving assembly, and the space moving assembly is fixedly connected with a C-shaped frame 5.
The space moving assembly includes: four first guide rails 17 fixedly connected with the base frame 1, and a moving plate 18 is slidably arranged on the first guide rails 17. The moving plate 18 controls the longitudinal movement of the C-frame 5.
The moving plate 18 is driven by a first drive motor 19. An output shaft of the first driving motor 19 is connected with a lead screw, and the lead screw drives the moving plate 18 to move along the length direction of the first guide rail 17.
The moving plate 18 is fixedly connected with two second guide rails 20, and the C-shaped frame 5 is driven by a second driving motor 21. The output shaft of the second driving motor 21 is fixedly connected with a lead screw, and the lead screw is matched with the C-shaped frame 5.
The C-shaped frame 5 moves along the length of the second guide rail 20. The first drive motor 19 and the second drive motor 21 are both servo motors.
A pressure detection assembly is arranged right above one station platform 28 of the disc 4, a lower die supporting assembly is arranged right below the pressure detection assembly, the pressure detection assembly and the lower die supporting assembly are both fixedly connected with the C-shaped frame 5, and the lower die supporting assembly is arranged below the disc 4.
As shown in fig. 2 and 4, the lower mold support assembly includes: a first cylinder 2 fixedly connected with the C-shaped frame 5 and a bottom plate 7. The telescopic rod of the first cylinder 2 is fixedly connected with a slide block 8, and the bottom plate 7 is provided with a dovetail groove 9 for the slide block 8 to slide. The dovetail groove 9 reduces the shaking of the sliding process of the sliding block 8, improves the stability of the sliding block 8 in the moving process, and prolongs the service life of the first cylinder 2.
A supporting block 10 is arranged right above the sliding block 8, a T-shaped groove 11 matched with the supporting block 10 is arranged on the bottom plate 7, a position blocking rib 12 matched with the T-shaped groove 11 is arranged on the supporting block 10, and the height of the position blocking rib 12 is smaller than that of the T-shaped groove 11.
The slider 8 is provided with a first inclined surface, and the supporting block 10 is provided with a second inclined surface matched with the first inclined surface. When the telescopic rod of the first cylinder 2 drives the first inclined plane of the sliding block 8 to contact with the second inclined plane, the sliding block 8 drives the supporting block 10 to move towards the lower surface of the disc 4 and contact with the lower surface of the disc 4, so that the riveting supporting effect is achieved.
The supporting block 10 is fixedly connected with four guide posts 13, and the guide posts 13 penetrate through the bottom plate 7 and extend to the outside. When the supporting block 10 moves upwards, the guide post 13 plays a role in guiding the supporting block 10, and the shaking of the supporting block 10 in the ascending process is reduced.
Supporting shoe 10 fixedly connected with four subassemblies that reset, the subassembly that resets is convenient for the telescopic link to drive supporting shoe 10 and return to initial position when 8 retract.
As shown in fig. 3, the reset assembly includes: a screw 14, a spring 15 and a gasket 16, wherein the screw 14 penetrates through the bottom plate 7 and is in threaded connection with the supporting block 10. The gasket 16 and the spring 15 are both sleeved on the screw 14, and the spring 15 is arranged between the bottom plate 7 and the gasket 16.
When the first cylinder 2 works, the telescopic rod drives the sliding block 8 to move along the dovetail groove 9 of the base, the first inclined plane is in contact with the second inclined plane, the supporting block 10 moves upwards, and riveting support is carried out on the disc 4.
When the first cylinder 2 retracts, the telescopic rod drives the sliding block 8 to move along the dovetail groove 9 of the bottom plate 7, the first inclined plane is separated from the second inclined plane, and the supporting block 10 moves downwards to form a certain gap with the lower surface of the disc 4. Avoiding friction with the support block 10 when the disc 4 rotates.
As shown in fig. 3, 5 and 6, a press-fitting power head is arranged above the rotary worktable, and is fixedly connected with a pressure detection assembly, and the press-fitting power head is preferably a servo electric cylinder 6. The pressure detection assembly includes: and one end of the fixing block 24 is fixedly connected with the servo electric cylinder 6, and the other end of the fixing block 24 is connected with a positioning block 25. The positioning block 25 and the fixing block 24 are provided with matching spaces communicated with each other. A sensor 26 and a punch head 27 are provided in the fitting space. When the servo electric cylinder 6 drives the punching head 27 to move downwards, the sensor 26 monitors the pressure in the riveting process. When the pressure reaches the set value, the servo electric cylinder 6 stops working.
In operation, as shown in fig. 1-6, a technician places a workpiece on the station assembly and controls the movement of the system via the switch. The control system drives the cam indexer 22 to work, and the cam indexer 22 drives the disk 4 to rotate 180 degrees.
The first driving motor 19 and the second driving motor 21 start to work, the first driving motor 19 drives the C-shaped frame 5 to move along the length direction of the first guide rail 17, and the second driving motor 21 drives the C-shaped frame 5 to move along the length direction of the second guide rail 20.
When the C-shaped frame 5 drives the stamping assembly to move to the riveting station, the first cylinder 2 drives the sliding block 8 to move, the first inclined plane is in contact with the second inclined plane, and the supporting block 10 moves upwards to be in contact with the lower surface of the disc 4.
The servo electric cylinder 6 drives the stamping head 27 to move downwards to rivet the workpiece, when the pressure in the riveting process reaches a set value, the sensor 26 feeds back the pressure to the control system, the control system gives an electric signal to the servo electric cylinder 6, and the servo electric cylinder 6 drives the stamping head 27 to move upwards.
Meanwhile, the telescopic rod of the first air cylinder 2 drives the sliding block 8 to move along the dovetail groove 9, the first inclined surface is separated from the second inclined surface, and the supporting block 10 moves to the initial position under the action of the spring 15.
The control system drives the first driving motor 19 and the second driving motor 21 to work again, and the C-shaped frame 5 moves to the next riveting point.
The first cylinder 2 drives the sliding block 8 to move, the first inclined plane is in contact with the second inclined plane, and the supporting block 10 moves upwards to be in contact with the lower surface of the disc 4.
The servo electric cylinder 6 drives the stamping head 27 to move downwards to rivet the workpiece, when the riveting pressure reaches a set value, the sensor 26 feeds back the riveting pressure to the control system, the control system gives an electric signal to the servo electric cylinder 6, and the servo electric cylinder 6 drives the stamping head 27 to move upwards.
The control system drives the press-fitting machine to perform riveting on different positions of the workpiece, and during the riveting process, a technician needs to take out a product on another station 28 and replace the unprocessed product.
After the riveting is completed, the control system drives the cam indexer 22 to rotate 180 degrees, and the riveting machine rivets the next product.
Various modifications to these embodiments will be readily apparent to those skilled in the art, and the generic principles defined herein may be applied to other embodiments without departing from the spirit or scope of the invention.