Disclosure of Invention
The invention aims to solve the technical problem of providing a multi-pose limb coordination rehabilitation training robot capable of realizing multi-pose upper limb rehabilitation training of a human body.
In order to solve the technical problems, the invention adopts the following technical scheme: the utility model provides a many postures limbs coordinate rehabilitation training robot, includes supporting mechanism, supporting mechanism's left side and/or right side are equipped with upper limbs rehabilitation training device, upper limbs rehabilitation training device includes that support, angle are connected adjustably frame on the support and connection are in be used for driving the upper limbs in the frame and carry out the upper limbs training ware of motion.
Further, the upper limb trainer is a five-bar mechanism, and the five-bar mechanism comprises a first crank, a first connecting rod, a second connecting rod, a first sliding block and a guide rail; one end of the first crank is rotatably installed on the rack, the other end of the first crank is hinged to one end of the first connecting rod, the other end of the first connecting rod is hinged to one end of the second connecting rod, the other end of the second connecting rod is hinged to the first sliding block, and the first sliding block is connected to the guide rail in a sliding mode.
Furthermore, the five-bar mechanism further comprises a crank driving mechanism for driving the first crank to rotate and a slide block driving mechanism for driving the first slide block to reciprocate along the guide rail.
Further, the five-rod mechanism also comprises a handle connected to the first connecting rod in a position-adjustable manner.
Further, the frame is connected to the support in an angle-adjustable manner through the following structure: the lower extreme of frame is connected with the supporting shoe, the rigid coupling has the back shaft on the supporting shoe, the back shaft rotates to be installed on the support, it has more than two jacks along its circumference interval distribution to open on the supporting shoe, be provided with the internal thread sleeve on the support, a threaded rod passes the internal thread sleeve insert establish in arbitrary one jack just the threaded rod with the internal thread sleeve forms the screw pair.
Further, the left side and the right side of the supporting mechanism are respectively provided with a protective tool, and the protective tool comprises more than one protective plate and a telescopic mechanism used for driving the protective plates to move left and right.
Further, telescopic machanism includes first motor and first lead screw, the outside of backplate is connected with cuts the fork expansion bracket, it has second sleeve and screw nut respectively to cut two link in the outside of fork expansion bracket, the second sleeve cover is established on the first lead screw, screw nut threaded connection is in on the first lead screw.
Further, the screw thread turning directions of the front portion and the rear portion of the first lead screw are opposite, the two guard plates are configured, and the lead screw nuts on the scissor type telescopic frames on the two guard plates are respectively in threaded connection with the front portion and the rear portion of the first lead screw.
Further, still include the low limbs training ware, the low limbs training ware is including rotating the second crank of installation, the second crank is articulated continuous with the one end of gangbar, the other end of gangbar articulates there is the link, link position connects adjustably on the second connecting rod.
Furthermore, the linkage rod is of a length-adjustable structure.
The invention has the beneficial effects that:
the upper limb training device is combined with the support through the rack, and the angle of the rack is adjustable, so that the upper limb rehabilitation training with multiple poses of the human body, such as the upper limb rehabilitation training in standing, sitting and lying positions, can be realized.
The invention has flexible and compact structure and can be suitable for various main bodies such as seats, wheelchairs, beds and the like.
The invention can be suitable for the upper and lower limb cooperative rehabilitation training of different people and can realize the upper and lower limb cooperative rehabilitation training with multiple poses and trajectories for lying, sitting and standing.
The invention has wide application range and various rehabilitation training modes, and can realize active/passive training of the upper and lower limbs in the using process.
The invention realizes the motion training with different tracks and different amplitudes, so that the training device can adapt to the training of the same trainer in different rehabilitation periods and training poses, and can meet the requirement of the trainees with different heights to carry out rehabilitation training.
Drawings
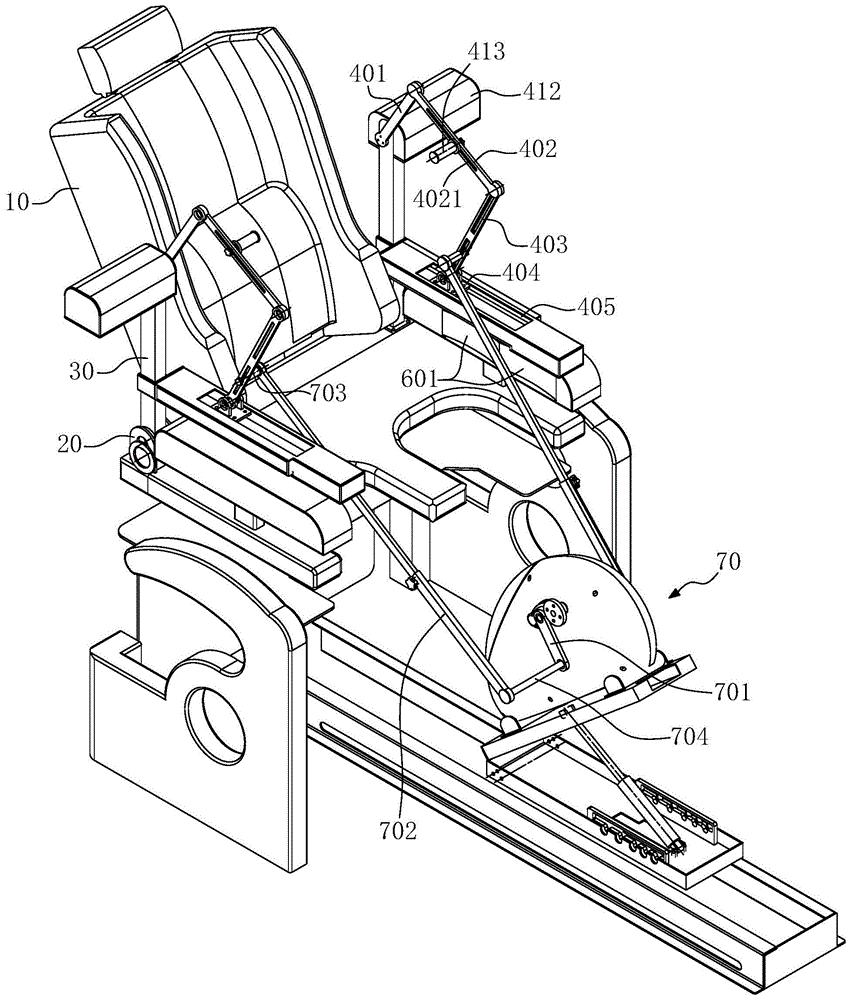
Fig. 1 is a schematic structural diagram of an embodiment of the present invention.
Fig. 2 is a schematic structural diagram of a slider driving mechanism according to an embodiment of the present invention.
Fig. 3 is a schematic structural view of a crank drive mechanism according to an embodiment of the present invention.
Fig. 4 is a schematic view of the mounting structure of the handle in one embodiment of the invention.
Fig. 5 is a schematic view of an installation structure of the rack and the support in an embodiment of the invention.
Fig. 6 is a sectional view B-B.
Fig. 7 is a cross-sectional view C-C.
Fig. 8 is a schematic structural diagram of a protector according to an embodiment of the invention.
Fig. 9 is a schematic view of the mounting structure of the footrest.
The components in the drawings are labeled as follows: the support mechanism 10, the support 20, the frame 30, the first crank 401, the first connecting rod 402, the sliding groove 4021, the second connecting rod 403, the first slider 404, the guide rail 405, the second motor 406, the second lead screw 407, the second torque sensor 408, the photoelectric sensor 409, the third motor 410, the third torque sensor 411, the housing 412, the handle 413, the second slider 414, the connecting rod 415, the rotating head 416, the support block 501, the insertion hole 5011, the limit block 5012, the support shaft 502, the internal threaded sleeve 503, the threaded rod 504, the first sleeve 505, the damper 506, the rotating disc 507, the limit bracket 508, the guard plate 601, the first motor 602, the first lead screw 603, the first torque sensor 604, the scissor type telescopic frame 605, the second sleeve 606, the lead screw nut 607, the lower limb trainer 70, the second crank 701, the linkage rod 702, the joint 703, the foot supporting rod 704 and the foot pedal 705.
Detailed Description
The present invention will be described in detail below with reference to the embodiments with reference to the attached drawings. It should be noted that the embodiments and features of the embodiments in the present application may be combined with each other without conflict.
See fig. 1.
The multi-posture limb coordination rehabilitation training robot comprises a supporting mechanism 10, wherein an upper limb rehabilitation training device is arranged on the left side and/or the right side of the supporting mechanism 10, and comprises a support 20, a machine frame 30 connected onto the support 20 in an angle-adjustable manner, and an upper limb trainer connected onto the machine frame 30 and used for driving an upper limb to move.
The upper limb training device is combined with the support through the rack, and the angle of the rack is adjustable, so that the upper limb rehabilitation training with multiple poses of the human body, such as the upper limb rehabilitation training in standing, sitting and lying positions, can be realized. In the present invention, the support mechanism 10 may be a chair as shown in the drawing, and may be a device for supporting the weight of a human body, which can perform a training mode suitable for other postures such as a lying posture.
In an embodiment, referring to fig. 1, the left and right sides of the support mechanism 10 are respectively provided with a protector, and the protector comprises more than one guard plate 601 and a telescopic mechanism for driving the guard plates 601 to move left and right. When the waist protector is used, the guard plates of the protectors on the left side and the right side are respectively clamped on the waist of a human body, and the waist protector plays a role in fixing during rehabilitation training.
In an embodiment, referring to fig. 8, the telescopic mechanism includes a first motor 602 and a first lead screw 603, a scissor-fork type telescopic frame 605 is connected to the outer side of the guard plate 601, two connection ends of the outer side of the scissor-fork type telescopic frame 605 are respectively hinged to a second sleeve 606 and a lead screw nut 607, the second sleeve 606 is sleeved on the first lead screw 603, and the lead screw nut 607 is in threaded connection with the first lead screw 603.
The motor is started, the motor drives the first lead screw to rotate, the lead screw nut can move on the first lead screw, the position of the second sleeve is fixed, the distance between the two connecting ends outside the scissor type telescopic frame is changed, the scissor type telescopic frame can stretch out and draw back, and therefore the guard plate is driven to move left and right.
Preferably, an output shaft of the first motor 602 is connected to the first lead screw 603 through a first torque sensor 604; the guard plate 601 is arc-shaped and has a higher degree of fit with a human body.
In one embodiment, the screw threads on the front and rear portions of the first lead screw 603 are opposite, the two guard plates 601 are configured, and the lead screw nuts 607 on the scissor-type telescopic frames 605 on the two guard plates 601 are respectively screwed on the front and rear portions of the first lead screw 603. By the design, the two guard plates are not interfered with each other in a telescopic mode, only one set of driving is needed, the guard plates can be selected as required during use, and the practicability is better.
In specific implementation, the protective plate 601 may be adhered with a material for increasing comfort, such as a sponge pad.
In one embodiment, the upper limb trainer is a five-bar mechanism comprising a first crank 401, a first link 402, a second link 403, a first slider 404 and a guide 405; one end of the first crank 401 is rotatably mounted on the frame 30, the other end of the first crank 401 is hinged to one end of the first connecting rod 402, the other end of the first connecting rod 402 is hinged to one end of the second connecting rod 403, the other end of the second connecting rod 403 is hinged to the first slider 404, and the first slider 404 is slidably connected to the guide rail 405.
In one embodiment, referring to FIG. 1, the five-bar mechanism further comprises a handle 413 adjustably coupled to the first link 402. The handle is used for the staff to hold, realizes driving the upper limbs motion, and position adjustable design, how can make the device be applicable to different people's exercise demand.
In one embodiment, referring to fig. 1 and 4, the handle 413 is adjustably coupled to the first link 402 by: the first connecting rod 402 is provided with a sliding slot, a second sliding block 414 is slidably connected in the sliding slot, the handle 413 is connected with a connecting rod 415, and the connecting rod 415 passes through the second sliding block 414 and the first connecting rod 402 and is locked on the first connecting rod 402 through a rotating head 416 which is connected to the connecting rod 415 through threads. In a specific implementation, the rotating head 416 is screwed on a portion of the connecting rod 415 that penetrates through the second slider 414 and the first connecting rod 402.
The rotating head is screwed up, the static friction force between the second sliding block and the side wall of the sliding groove is increased, the second sliding block cannot move, the rotating head is unscrewed, the static friction force between the second sliding block and the sliding groove is reduced, and the second sliding block can move freely, so that the handle can be moved and fixed. The installation mode is very convenient and quick to operate and high in practicability.
The five-rod mechanism has two degrees of freedom, and when the five-rod mechanism is used, the first crank is driven to rotate and the sliding block is driven to reciprocate, so that the handle on the first connecting rod is driven to move in an elliptic track, and when a hand is held on the handle, the upper limb can be used for performing the rehabilitation training of stretching and bending.
Preferably, each hinge of the five-rod mechanism forms a rotating pair by using a rolling bearing. To improve the smoothness of rotation; the guide rail 405 is attached to the frame 30. No additional parts are needed to support the guide rail 405, and the support design is more reasonable.
In an embodiment, the five-bar mechanism further comprises a crank driving mechanism for driving the first crank 401 to rotate.
In one embodiment, the five-bar mechanism further comprises a slider driving mechanism for driving the first slider 404 to reciprocate along the guide rail 405.
In an embodiment, referring to fig. 2, the slide block driving mechanism includes a second motor 406 and a second lead screw 407, the second lead screw 407 is rotatably mounted on the guide rail 405, the first slide block 404 is disposed on the lead screw and is in threaded fit with the second lead screw 407, and an output shaft of the second motor 406 is connected with the second lead screw 407. Preferably, the output shaft of the second motor 406 is connected to the second lead screw 407 through a second torque sensor 408. The sliding block driving mechanism is simple in structure and easy to implement, and can smoothly and accurately drive the first sliding block to reciprocate along the guide rail.
In an embodiment, two ends of the guide rail 405 are respectively and fixedly provided with a photoelectric sensor 409 for monitoring the position of the first slider 404, and when the first slider 404 slides to the two ends of the guide rail 405, the second motor 406 automatically rotates reversely, so that the first slider 404 moves in the opposite direction, and the distance that the first slider 404 moves left and right is limited.
In one embodiment, referring to fig. 3, the crank driving mechanism comprises a third motor 410, and an output shaft of the third motor 410 is connected to one end of the first crank 401. Preferably, an output shaft of the third motor 410 is connected to one end of the first crank 401 through a third torque sensor 411.
In one embodiment, the crank driving mechanism further includes a housing 412, the third motor 410 is disposed in the housing 412, and the housing 412 is fixed to the frame 30. The casing plays the guard action, and it sets up in the frame, and the structure has more the wholeness.
The torque sensors are used for detecting the torque and the power output by the motor, and the monitoring accuracy is improved.
In one embodiment, referring to fig. 4-7, the frame 30 is angularly adjustably coupled to the support base 20 by: the lower end of the rack 30 is connected with a supporting block 501, a supporting shaft 502 is fixedly connected to the supporting block 501, the supporting shaft 502 is rotatably mounted on the support 20, more than two insertion holes 5011 are formed in the supporting block 501 and are distributed at intervals along the circumferential direction of the supporting block, an internal thread sleeve 503 is arranged on the support 20, a threaded rod 504 penetrates through the internal thread sleeve 503 and is inserted into any one insertion hole 5011, and the threaded rod 504 and the internal thread sleeve 503 form a screw pair.
The rack can rotate relative to the support through the support shaft to carry out angle adjustment, and after the angle adjustment is good, the rack is inserted into the corresponding insertion hole through the threaded rod 504 to realize the positioning of the rack. The internal thread sleeve plays a role in fixing the threaded rod.
In a specific implementation, two ends of the supporting shaft 502 are rotatably mounted on the support 20 through rolling bearings, respectively, so as to ensure smooth rotation; the outer end of the threaded rod 504 is connected with a rotary disc 507 to facilitate the application of external force to rotate the threaded rod.
In one embodiment, the insertion hole 5011 is tapered, and the portion of the threaded rod 504 inserted into the insertion hole 5011 is also tapered, so that the design has a guiding function to facilitate the insertion of the thread into the insertion hole.
In one embodiment, the supporting shaft 502 is sleeved with a first sleeve 505, and the first sleeve 505 is connected with a damper 506 contacting with the support 20. The damper is used for preventing the frame from swinging freely.
In an embodiment, the supporting device further includes a limiting bracket 508, and a limiting block 5012 for forming a limiting fit with the limiting bracket 508 is disposed on the supporting block 501. Design like this, when the supporting shoe rotated the stopper on it and contradicted to spacing support, the supporting shoe stopped rotating promptly to the rotation range to the supporting shoe is restricted, prevents to rotate too much, the operation of being convenient for.
In one embodiment, the supporting block 501 is in a shape of a circular disc, the position-limiting bracket 508 is in a shape of a circular arc, and the supporting block 501 is supported on the position-limiting bracket 508 and is matched with the position-limiting bracket 508. By the design, the limiting bracket can support the supporting block and does not prevent the supporting block from rotating to adjust the angle.
In one embodiment, the lower limb trainer 70 is further comprised, the lower limb trainer 70 comprises a second crank 701 which is rotatably arranged, the second crank 701 is hinged with one end of a linkage rod 702, the other end of the linkage rod 702 is hinged with a connecting piece 703, and the connecting piece 703 is connected on the second connecting rod 403 in a position-adjustable manner.
The lower limb trainer of the exercise bicycle type can be formed through the second crank, and the training effect is good. Through the design, the first sliding block is driven to reciprocate through the rotation of the crank and the second motor, and the whole five-rod mechanism can also be driven to move, so that the upper limb and the lower limb can be cooperatively trained. The first motor does not rotate at this time.
In a specific implementation, the second crank 701 is hinged to one end of the linkage rod 702 through a foot support rod 704, the foot support rod 704 is used for supporting the foot, and preferably, a foot pedal 705 is installed on the foot support rod 704, as shown in fig. 9, so that the foot can be better supported for training.
In one embodiment, the connecting member 703 can be connected in a position adjustable manner by using a handle.
In one embodiment, the linkage 702 is a length adjustable structure. The length adjustable rod is a common part in the field, and the realization structural style of the length adjustable rod is various, such as a selfie stick structure and the like, wherein a telescopic loop bar is illustrated in the figure, and a locking screw is adopted to realize the positioning structure.
In specific implementation, the left upper limb rehabilitation training device and the right upper limb rehabilitation training device and the left crank and the right crank are arranged, so that the two upper limbs and the two lower limbs correspond to each other one by one to realize linkage through the linkage rods.
In one embodiment, the lower limb trainer is arranged on an angle adjusting frame, the angle adjusting frame is fixed on the ground, and the size of the angle is adjusted to realize the lower limb multi-position exercise training.
The invention can be applied to the rehabilitation training of people with reduced or lost motion functions of upper and lower limbs, helps the people to realize the rehabilitation training under the standard motion tracks with various poses, and has the advantages of low energy consumption, high cost performance, wide application range and very large industrial application prospect.
It should be understood that the examples and embodiments described herein are for illustrative purposes only and are not intended to limit the scope of the present disclosure, and that various modifications or changes in light thereof will be suggested to persons skilled in the art and are to be included within the spirit and purview of this disclosure.