CN108214120B - Axe polishing robot - Google Patents

Axe polishing robot Download PDF

Info

Publication number
CN108214120B
CN108214120B CN201810014513.6A CN201810014513A CN108214120B CN 108214120 B CN108214120 B CN 108214120B CN 201810014513 A CN201810014513 A CN 201810014513A CN 108214120 B CN108214120 B CN 108214120B
Authority
CN
China
Prior art keywords
component
polishing
clamping
axe
feeding
Prior art date
Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
Active
Application number
CN201810014513.6A
Other languages
Chinese (zh)
Other versions
CN108214120A (en
Inventor
不公告发明人
Current Assignee (The listed assignees may be inaccurate. Google has not performed a legal analysis and makes no representation or warranty as to the accuracy of the list.)
Xi'an Magic Point Information Technology Co.,Ltd.
Original Assignee
Quanzhou Qixin Patent Technology Consulting Co ltd
Priority date (The priority date is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the date listed.)
Filing date
Publication date
Application filed by Quanzhou Qixin Patent Technology Consulting Co ltd filed Critical Quanzhou Qixin Patent Technology Consulting Co ltd
Priority to CN201810014513.6A priority Critical patent/CN108214120B/en
Publication of CN108214120A publication Critical patent/CN108214120A/en
Application granted granted Critical
Publication of CN108214120B publication Critical patent/CN108214120B/en
Active legal-status Critical Current
Anticipated expiration legal-status Critical

Links

Images

Classifications

    • B—PERFORMING OPERATIONS; TRANSPORTING
    • B24—GRINDING; POLISHING
    • B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
    • B24B3/00—Sharpening cutting edges, e.g. of tools; Accessories therefor, e.g. for holding the tools
    • B24B3/60—Sharpening cutting edges, e.g. of tools; Accessories therefor, e.g. for holding the tools of tools not covered by the preceding subgroups
    • B—PERFORMING OPERATIONS; TRANSPORTING
    • B24—GRINDING; POLISHING
    • B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
    • B24B41/00—Component parts such as frames, beds, carriages, headstocks
    • B24B41/005—Feeding or manipulating devices specially adapted to grinding machines
    • B—PERFORMING OPERATIONS; TRANSPORTING
    • B24—GRINDING; POLISHING
    • B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
    • B24B41/00—Component parts such as frames, beds, carriages, headstocks
    • B24B41/06—Work supports, e.g. adjustable steadies

Landscapes

  • Engineering & Computer Science (AREA)
  • Mechanical Engineering (AREA)
  • Finish Polishing, Edge Sharpening, And Grinding By Specific Grinding Devices (AREA)
  • Constituent Portions Of Griding Lathes, Driving, Sensing And Control (AREA)

Abstract

一种斧头打磨机器人,属于斧头生产设备领域。是由按压组件、上料组件、下料组件、底板、气泵、打磨组件和夹压组件组成的,所述按压组件的下方设置有打磨组件,所述按压组件和夹压组件相连,所述打磨组件的右侧设置有上料组件,所述上料组件的一侧设置有下料组件,所述按压组件、上料组件、下料组件、气泵、打磨组件和夹压组件皆安装在底板上。通过按压组件、夹压组件、打磨组件之间的配合,可以有效的实现对于斧头的双面打磨,提高工作效率,同时通过上料组件和下料组件的配合,可以实现斧头的上下料,提高工作效率,可以同时进行多把斧头的加工。
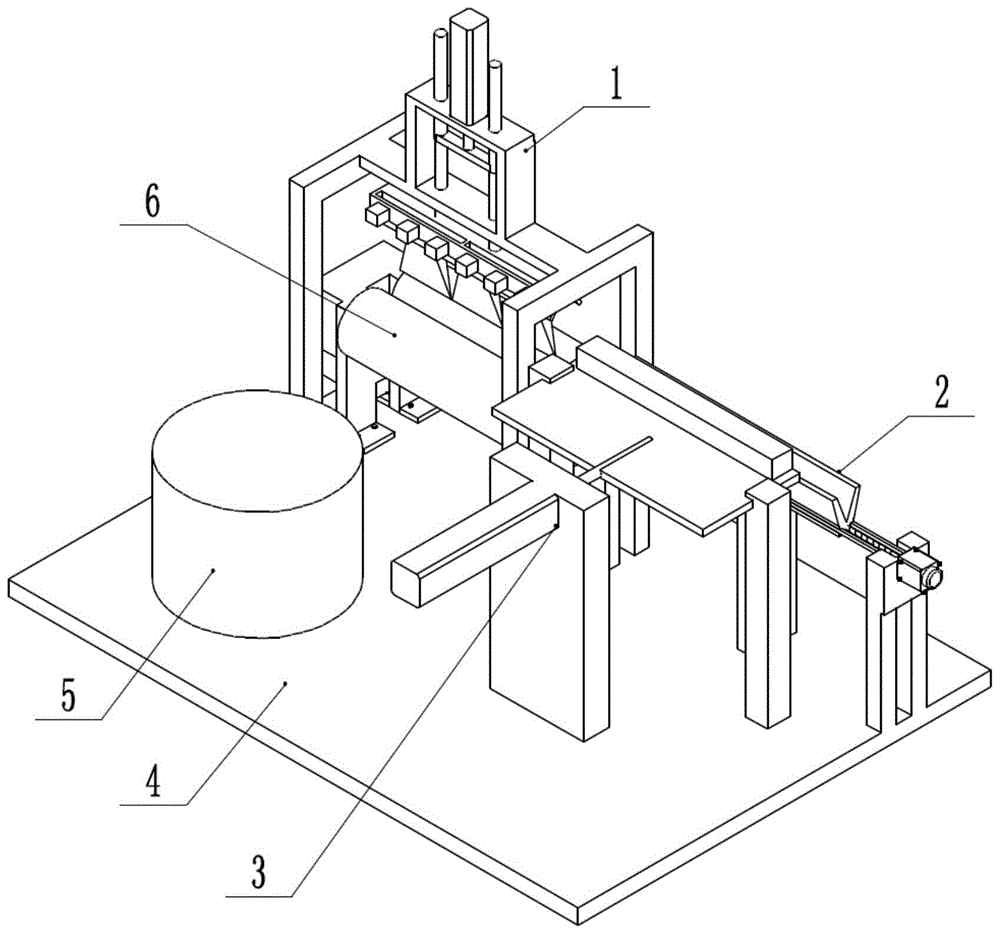
Figure 201810014513

An axe grinding robot belongs to the field of axe production equipment. It is composed of a pressing component, a feeding component, an unloading component, a bottom plate, an air pump, a grinding component and a clamping component. A grinding component is arranged below the pressing component, and the pressing component and the clamping component are connected. The right side of the assembly is provided with a feeding assembly, one side of the feeding assembly is provided with a feeding assembly, and the pressing assembly, the feeding assembly, the feeding assembly, the air pump, the grinding assembly and the clamping assembly are all installed on the bottom plate . Through the cooperation between the pressing component, the clamping component and the grinding component, the double-sided grinding of the axe head can be effectively achieved, and the work efficiency can be improved. Work efficiency, can process multiple axes at the same time.

Figure 201810014513

Description

Axe polishing robot
Technical Field
The invention relates to an axe grinding robot, and belongs to the field of axe production equipment.
Background
The axe is a tool often practical in people's daily life, in the production process of current axe, often need the workman to polish by hand, open one's edge, the axe is at the in-process of polishing, often the workman carries out the centre gripping through purpose-made instrument with single axe, then polish on the emery wheel, at this in-process, because specific operational environment, fixed work posture has just also decided this work has great intensity of labour, simultaneously at the during operation, because the piece that produces after the friction mixes among the air, long this in the past, also can cause great harm to workman's respiratory, bring occupational disease from this, but do not have corresponding apparatus for producing at present in the market to solve above-mentioned problem, for this reason need an axe polishing robot.
Disclosure of Invention
In order to overcome the defects, the invention provides an axe polishing robot.
The invention is realized by the following technical scheme: the axe polishing robot comprises a pressing assembly, a feeding assembly, a discharging assembly, a bottom plate, an air pump, a polishing assembly and a clamping assembly, wherein the polishing assembly is arranged below the pressing assembly, the pressing assembly is connected with the clamping assembly, the feeding assembly is arranged on the right side of the polishing assembly, the discharging assembly is arranged on one side of the feeding assembly, and the pressing assembly, the feeding assembly, the discharging assembly, the air pump, the polishing assembly and the clamping assembly are all arranged on the bottom plate.
Furthermore, the pressing assembly comprises a first air cylinder, a guide rod, a first air cylinder mounting frame, a connecting transverse plate and a first support frame, the first air cylinder is mounted on the first air cylinder mounting frame, the connecting transverse plate is mounted on a push rod of the first air cylinder, the guide rod is mounted at two ends of the connecting transverse plate, and the lower end of the guide rod is connected with the clamping assembly.
Further, the upper end of the guide rod penetrates the first cylinder mounting bracket.
Further, the material loading subassembly comprises slide rail, lead screw, feed motor and second support frame, casing, draw-in groove, spout, base frame and mating holes, the slide rail has two, the slide rail sets up the inboard at the second support frame, install feed motor on the second support frame, be connected with the lead screw on feed motor's the output shaft, the mating holes cooperation installation on lead screw and the base frame, the both sides of base frame are provided with the spout, the upper end of base frame sets up the casing, the inside draw-in groove that is provided with of casing.
Furthermore, the clamping groove is in a V-shaped groove shape.
Furthermore, the blanking assembly comprises three support frames, two electromagnets, a push plate, a fourth support frame and a push-pull cylinder, the push plate is arranged in the middle of the two third support frames and slides in a matched manner with the top ends of the three support frames, the electromagnets are installed at one end, close to the feeding assembly, of the push plate, the other end of the push plate is connected with a push rod of the push-pull cylinder, and the push-pull cylinder is installed on the fourth support frame.
Furthermore, the subassembly of polishing comprises location base plate, grinding motor, transmission case, first dull polish roller and second dull polish roller, location base plate upper end intermediate position is provided with first dull polish roller and second dull polish roller, the tip and the transmission case of first dull polish roller and second dull polish roller are connected, the input of transmission case is provided with grinding motor.
Furthermore, the clamping assembly comprises a clamping cylinder, a push rod, an upper base body, a positioning plate, a guide port, a positioning groove, a return groove and a connector, the positioning groove is arranged at the lower end of the upper base body, the guide port is arranged at the lower end of the positioning groove, the positioning plate is arranged at two ends of the positioning groove, the clamping cylinder is distributed on the positioning plate, the connector is arranged on the upper base body, and the push rod penetrates through the positioning plate and the upper base body.
The double-side grinding axe has the beneficial effects that through the matching among the pressing component, the clamping component and the grinding component, the double-side grinding of the axe can be effectively realized, the working efficiency is improved, meanwhile, through the matching of the feeding component and the discharging component, the feeding and discharging of the axe can be realized, the working efficiency is improved, and the processing of multiple axes can be simultaneously carried out.
Drawings
FIG. 1 is a schematic view of the overall structure of the present invention;
FIG. 2 is an isometric view of the present invention;
FIG. 3 is a schematic structural view of the present invention with the loading assembly and the unloading assembly removed;
FIG. 4 is an isometric view of the crimp assembly;
FIG. 5 is a schematic view of a clamping assembly;
FIG. 6 is a partial structural schematic diagram of the feeding assembly and the blanking assembly;
fig. 7 is a partial structure schematic diagram of the feeding assembly.
In the figure, 1, a pressing component, 101, a first air cylinder, 102, a guide rod, 103, a first air cylinder mounting frame, 104, a connecting transverse plate, 105, a first supporting frame, 2, a feeding component, 201, a sliding rail, 202, a lead screw, 203, a feeding motor, 204, a second supporting frame, 205, a shell, 206, a clamping groove, 207, a sliding groove, 208, a bottom table, 209, a matching hole, 3, a blanking component, 301, a third supporting frame, 302, an electromagnet, 303, a push plate, 304, a fourth supporting frame, 305, a push-pull air cylinder, 4, a bottom plate, 5, an air pump, 6, a grinding component, 601, a positioning base plate, 602, a grinding motor, 603, a transmission box, 604, a first grinding roller, 605, a second grinding roller, 7, a clamping component, 701, a clamping air cylinder, 702, a push rod, 703, an upper base body, 704, a positioning plate, 705, a guide port, 706, a positioning groove, 707, a return groove, 708, a, 8. an axe.
Detailed Description
An axe polishing robot comprises a pressing component 1, a feeding component 2, a discharging component 3, a bottom plate 4, an air pump 5, a polishing component 6 and a clamping component 7, wherein the polishing component 6 is arranged below the pressing component 1, the pressing component 1 is connected with the clamping component 7, the feeding component 2 is arranged on the right side of the polishing component 6, the discharging component 3 is arranged on one side of the feeding component 2, and the pressing component 1, the feeding component 2, the discharging component 3, the air pump 5, the polishing component 6 and the clamping component 7 are all arranged on the bottom plate 4.
Furthermore, the pressing assembly 1 is composed of a first cylinder 101, a guide rod 102, a first cylinder mounting frame 103, a connecting transverse plate 104 and a first supporting frame 105, the first cylinder 101 is mounted on the first cylinder mounting frame 103, the connecting transverse plate 104 is mounted on a push rod of the first cylinder 101, the guide rod 102 is mounted at two ends of the connecting transverse plate 104, and the lower end of the guide rod 102 is connected with the clamping assembly 7.
Further, the upper end of the guide rod 102 penetrates the first cylinder mounting bracket 103.
Furthermore, the feeding assembly 2 is composed of two sliding rails 201, a screw 202, two feeding motors 203, two second supporting frames 204, a shell 205, a clamping groove 206, two sliding grooves 207, a bottom table 208 and two matching holes 209, the sliding rails 201 are arranged on the inner side of the second supporting frames 204, the feeding motors 203 are installed on the second supporting frames 204, the screw 202 is connected to output shafts of the feeding motors 203, the screw 202 and the matching holes 209 on the bottom table 208 are installed in a matching mode, the sliding grooves 207 are arranged on two sides of the bottom table 208, the shell 205 is arranged at the upper end of the bottom table 208, and the clamping groove 206 is arranged inside the shell 205.
Further, the shape of the slot 206 is a V-shaped slot.
Furthermore, the blanking assembly 3 is composed of three support frames 301, electromagnets 302, push plates 303, fourth support frames 304 and push-pull cylinders 305, there are two third support frames 301, the push plates 303 are arranged in the middle of the two third support frames 301, the push plates 303 slide with the top ends of the third support frames 301 in a matching manner, the electromagnets 302 are installed at one ends of the push plates 303 close to the feeding assembly 2, the other ends of the push plates 303 are connected with push rods of the push-pull cylinders 305, and the push-pull cylinders 305 are installed on the fourth support frames 304.
Furthermore, the grinding assembly 6 is composed of a positioning substrate 601, a grinding motor 602, a transmission case 603, a first grinding roller 604 and a second grinding roller 605, the first grinding roller 604 and the second grinding roller 605 are arranged at the middle position of the upper end of the positioning substrate 601, the end parts of the first grinding roller 604 and the second grinding roller 605 are connected with the transmission case 603, and the grinding motor 602 is arranged at the input end of the transmission case 603.
Furthermore, the clamping assembly 7 is composed of a clamping cylinder 701, a push rod 702, an upper base 703, a positioning plate 704, a guide port 705, a positioning groove 706, a return groove 707, and a connection port 708, wherein the positioning groove 706 is disposed at the lower end of the upper base 703, the guide port 705 is disposed at the lower end of the positioning groove 706, the positioning plates 704 are mounted at two ends of the positioning groove 706, the clamping cylinder 701 is distributed on the positioning plates 704, the connection port 708 is disposed on the upper base 703, and the push rod 703 penetrates through the positioning plate 704 and the upper base 703.
The working principle is as follows: when the device works, firstly, the device is switched on, an axe which is not ground is vertically placed downwards in the clamping groove 206, the bottom table 208 is pushed into the lower part of the clamping and pressing component 7 through the feeding motor 203, the clamping and pressing component 7 is moved downwards under the work of the first air cylinder 101 in the pressing component 1, under the action of the guide port 705, the clamping and pressing component 7 can overcome small errors to swallow the end part of the axe, the end part of the axe enters the positioning groove 706, meanwhile, the positioning of the axe is realized through the work of the clamping and pressing air cylinder 701, the feeding component 2 is reset, the clamping and pressing component 7 is pushed downwards under the action of the first air cylinder 101, at the moment, the grinding component 6 works, the rotation direction of the grinding component 6 is the tangential acceleration direction, the axe is vertically upwards, the rotation directions of the first grinding roller 604 and the second grinding roller are opposite to the rotation direction 605, after grinding is finished, the axe is retracted through the feeding component 2, and at the same time, the axe is taken down from the clamping groove 26 through the cooperation of, and finishing the primary grinding work of the axe.
It will be appreciated by those skilled in the art that changes, modifications, substitutions and alterations can be made in the embodiments described above without departing from the principles and spirit of the invention, the scope of which is defined by the appended claims.

Claims (6)

1. The utility model provides an axe polishing robot, is by pressing subassembly, material loading subassembly, unloading subassembly, bottom plate, air pump, polishing subassembly and clamp and press the subassembly to constitute, its characterized in that: the lower part of the pressing component is provided with a polishing component, the pressing component is connected with a clamping component, the right side of the polishing component is provided with a feeding component, one side of the feeding component is provided with a discharging component, the pressing component, the feeding component, the discharging component, an air pump, the polishing component and the clamping component are all arranged on a bottom plate, the pressing component consists of a first air cylinder, a guide rod, a first air cylinder mounting frame, a connecting transverse plate and a first support frame, the first air cylinder is arranged on the first air cylinder mounting frame, the connecting transverse plate is arranged on the popularization of the first air cylinder, the guide rods are arranged at two ends of the connecting transverse plate, the lower end of the guide rod is connected with the clamping component, the clamping component consists of a clamping air cylinder, a push rod, an upper base body, a positioning plate, a guide port, a positioning groove, a return groove and a connecting port, the lower end of the upper base body is provided with a, the lower extreme of constant head tank is provided with the guide way, the locating plate is installed at the both ends of constant head tank, it has the clamping cylinder to distribute on the locating plate, be provided with the connector on the last base member, the push rod runs through locating plate and last base member.
2. An axe grinding robot as recited in claim 1, further comprising: the upper end of the guide rod penetrates through the first cylinder mounting frame.
3. An axe grinding robot as recited in claim 2, further comprising: the feeding assembly comprises a sliding rail, two screw rods, a feeding motor, a second support frame, a shell, a clamping groove, a sliding groove, a bottom platform and matching holes, the sliding rail is arranged on the inner side of the second support frame, the feeding motor is installed on the second support frame, the screw rods are connected onto output shafts of the feeding motor, the matching holes in the screw rods and the bottom platform are installed in a matched mode, the sliding grooves are formed in the two sides of the bottom platform, the shell is arranged at the upper end of the bottom platform, and the clamping groove is formed in the shell.
4. An axe grinding robot as recited in claim 3, further comprising: the clamping groove is in a V-shaped groove shape.
5. An axe grinding robot as recited in claim 3, further comprising: the blanking assembly comprises three support frames, two electromagnets, a push plate, a fourth support frame and a push-pull cylinder, the push plate is arranged in the middle of the two third support frames and slides in a matched manner with the top ends of the three support frames, the electromagnet is installed at one end, close to the feeding assembly, of the push plate, the other end of the push plate is connected with a push rod of the push-pull cylinder, and the push-pull cylinder is installed on the fourth support frame.
6. An axe grinding robot as recited in claim 5, further comprising: the polishing assembly comprises a positioning substrate, a polishing motor, a transmission case, a first polishing roller and a second polishing roller, wherein the first polishing roller and the second polishing roller are arranged at the middle position of the upper end of the positioning substrate, the end part of the first polishing roller and the end part of the second polishing roller are connected with the transmission case, and the polishing motor is arranged at the input end of the transmission case.
CN201810014513.6A 2018-01-08 2018-01-08 Axe polishing robot Active CN108214120B (en)

Priority Applications (1)

Application Number Priority Date Filing Date Title
CN201810014513.6A CN108214120B (en) 2018-01-08 2018-01-08 Axe polishing robot

Applications Claiming Priority (1)

Application Number Priority Date Filing Date Title
CN201810014513.6A CN108214120B (en) 2018-01-08 2018-01-08 Axe polishing robot

Publications (2)

Publication Number Publication Date
CN108214120A CN108214120A (en) 2018-06-29
CN108214120B true CN108214120B (en) 2020-05-08

Family

ID=62644796

Family Applications (1)

Application Number Title Priority Date Filing Date
CN201810014513.6A Active CN108214120B (en) 2018-01-08 2018-01-08 Axe polishing robot

Country Status (1)

Country Link
CN (1) CN108214120B (en)

Families Citing this family (2)

* Cited by examiner, † Cited by third party
Publication number Priority date Publication date Assignee Title
CN108581655A (en) * 2018-08-15 2018-09-28 长沙学院 A kind of fully-automatic household knife sharpener
CN116423304B (en) * 2023-06-14 2023-08-11 山东磐古实业有限公司 Auxiliary assembly is polished to axe piece of aluminium alloy axe processing production

Family Cites Families (2)

* Cited by examiner, † Cited by third party
Publication number Priority date Publication date Assignee Title
CN202704543U (en) * 2012-08-03 2013-01-30 陈星树 Automatic loading and unloading device
CN106985006A (en) * 2017-04-13 2017-07-28 宁波天和电动工具有限公司 A kind of double bistrique type knife sharpeners of two-sided cooling and its sharpening method

Also Published As

Publication number Publication date
CN108214120A (en) 2018-06-29

Similar Documents

Publication Publication Date Title
CN104191886B (en) The two-sided engraving machine of a kind of wooden door leaf
CN110757313B (en) A highly efficient automatic loading and unloading polishing machine
CN116141402A (en) A processing device for parts of power supply equipment
CN104551957B (en) Semi-automatic brush change device
CN212526326U (en) Synchronous polishing work station
CN221849632U (en) A shaping and finishing device for annular stamping parts
CN210025598U (en) Solid wood furniture processing device
CN108214120A (en) A kind of axe milling robot
CN219747238U (en) A combined hydraulic clamp for workpiece processing
CN218984265U (en) Small part rapid machining operation table
CN218167934U (en) Paint scraping jig
CN214518723U (en) Full-automatic USB assembling equipment
CN213765409U (en) Feeding mechanism used on glass hanging piece grinding and polishing machine
CN212170399U (en) A high-efficiency automatic loading and unloading manipulator equipment
CN111195838A (en) Aluminum substrate polishing equipment
CN210745878U (en) Material bearing device of high-speed chip mounter
CN210818281U (en) Automatic unloading mechanism of going up of ring gear
CN219562511U (en) Knife and sword processing clamping device
CN222726327U (en) Double-sided surface grinding device for zirconia ceramic knife
CN209336368U (en) A kind of carving machine that material frame is rear-mounted
CN207629817U (en) A rotary driven cylindrical sleeve processing and polishing mechanism
CN113510596B (en) Feeding mechanism of polishing machine for bolt machining
CN214212813U (en) Sheet Mounting Equipment
CN221390188U (en) Motor frame end surface polishing device for water pump
CN223863500U (en) High-efficient and high-precision automatic sharpening device

Legal Events

Date Code Title Description
PB01 Publication
PB01 Publication
SE01 Entry into force of request for substantive examination
TA01 Transfer of patent application right

Effective date of registration: 20200414

Address after: 362000 Luoyang Town, Huian County, Quanzhou City, Fujian Province, Du CuO No. 164

Applicant after: QUANZHOU QIXIN PATENT TECHNOLOGY CONSULTING Co.,Ltd.

Address before: 252325 Anle Town, Yanggu County, Liaocheng City, Shandong Province

Applicant before: Li Zhengmeng

GR01 Patent grant
GR01 Patent grant
TR01 Transfer of patent right

Effective date of registration: 20250808

Address after: 710000 Shaanxi Province, Xi'an City, Gaoxin District, No. 13 Gaoxin Fourth Road, Building 1, Unit 1, Room 12610

Patentee after: Xi'an Magic Point Information Technology Co.,Ltd.

Country or region after: China

Address before: 362000 duo CuO 164, industrial and rural area, Luoyang Town, Huian County, Quanzhou, Fujian

Patentee before: QUANZHOU QIXIN PATENT TECHNOLOGY CONSULTING CO.,LTD.

Country or region before: China

PE01 Entry into force of the registration of the contract for pledge of patent right

Denomination of invention: A hatchet grinding robot

Granted publication date: 20200508

Pledgee: Xi'an Caijin Financing Guarantee Co.,Ltd.

Pledgor: Xi'an Magic Point Information Technology Co.,Ltd.

Registration number: Y2026980010188