CN103345260A - Connecting rod type double-shaft solar tracking mechanism - Google Patents
Connecting rod type double-shaft solar tracking mechanism Download PDFInfo
- Publication number
- CN103345260A CN103345260A CN2013102251141A CN201310225114A CN103345260A CN 103345260 A CN103345260 A CN 103345260A CN 2013102251141 A CN2013102251141 A CN 2013102251141A CN 201310225114 A CN201310225114 A CN 201310225114A CN 103345260 A CN103345260 A CN 103345260A
- Authority
- CN
- China
- Prior art keywords
- panel
- connecting rod
- fixed
- solar
- transmission shaft
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Landscapes
- Photovoltaic Devices (AREA)
Abstract
Description
技术领域 technical field
本发明涉及一种太阳能跟踪技术,具体说是一种连杆式双轴太阳能跟踪机构。 The present invention relates to a solar tracking technology, specifically a link-type dual-axis solar tracking mechanism.
背景技术 Background technique
随着人类社会的发展,能源问题已经成为各国议论的焦点,以清洁可再生能源为主的能源结构将是未来发展的必然,太阳能作为一种新型能源,具有储量无限,普遍存在,利用清洁,使用经济等优点。无疑将是未来发展的热点,但是,太阳能也存在着如低密度,间歇性,空间分布不断变换的缺点,这样就使得目前的一系列太阳能设备对太阳能的利用效率不高。 With the development of human society, energy issues have become the focus of discussion in various countries. The energy structure based on clean and renewable energy will be inevitable for future development. As a new type of energy, solar energy has unlimited reserves, ubiquity, clean utilization, Advantages of using economy and so on. Undoubtedly, it will be a hot spot for future development, but solar energy also has shortcomings such as low density, intermittent, and constantly changing spatial distribution, which makes the current series of solar energy equipment not efficient in utilizing solar energy.
据研究,在太阳能发电系统当中,同样的条件下,采用自动跟踪发电设备要比固定的发电设备提高发电量的30%。被目前大多数的太阳能电池板阵列基本上都是固定的,无法实现对阳光的跟踪,因而也就无法最大效率的利用太阳光,即使采用了跟踪阳光技术的光伏设备,机构仍有很多可以优化和改进的地方,例如,直接用直线电动推杆来推动太阳能电池板,对所用的直线电动推杆的推出行程要求较高。用回转驱动装置来实现跟踪设备的水平方向的旋转,使得整个系统在竖直方向的重量全部落在回转驱动装置上,因而必须采用更大功率的电机,大大增加成本,且寿命不高。 According to research, in the solar power generation system, under the same conditions, the use of automatic tracking power generation equipment can increase the power generation by 30% compared with fixed power generation equipment. At present, most of the solar panel arrays are basically fixed and cannot track the sunlight, so they cannot use the sunlight to the maximum efficiency. Even if the photovoltaic equipment with the technology of tracking sunlight is adopted, there are still many mechanisms that can be optimized. And improvements, for example, directly using a linear electric actuator to push the solar panel requires a higher push-out stroke of the linear electric actuator used. Using the slewing drive to realize the horizontal rotation of the tracking equipment makes the weight of the entire system in the vertical direction fall on the slewing drive. Therefore, a more powerful motor must be used, which greatly increases the cost and has a short life.
发明内容 Contents of the invention
本发明的目的在于克服以上的不足之处,提供一种连杆式双轴太阳能跟踪机构,该机构结构简单且成本低,能够最大效率的跟踪太阳光。 The purpose of the present invention is to overcome the above disadvantages and provide a link-type dual-axis solar tracking mechanism, which has a simple structure and low cost, and can track sunlight with maximum efficiency.
为达到上述目的,本发明的构思是: To achieve the above object, design of the present invention is:
本发明的连杆式双轴太阳能跟踪机构,在对太阳能电池板的俯仰运动实现和旋转运动实现均不同于传统的双轴太阳能跟踪机构。在本发明中,直线电动推杆水平安置在旋转面板上,直线电动推杆的伸缩端铰接有一连杆,该连杆的另一端铰接有另外两根连杆。直线电动推杆的推出和缩进导致三根连杆的动作,从而实现太阳能电池板的俯仰运动。这样做的优点是:首先,大大缩短的直线电动推杆的推出行程,直线电动推杆只需推出或缩进较小的距离就能通过连杆机构实现电池板较大幅度的俯仰运动。其次,由于直线电动推杆水平安放在旋转面板上,增加了系统的稳定性,并且减少了系统在旋转运动时,直线电动推杆和其余零件可能存在干涉的问题。 The connecting rod type dual-axis solar tracking mechanism of the present invention is different from the traditional dual-axis solar tracking mechanism in realizing the pitching motion and rotating motion of the solar panel. In the present invention, the linear electric push rod is horizontally arranged on the rotating panel, and the telescopic end of the linear electric push rod is hinged with a connecting rod, and the other end of the connecting rod is hinged with other two connecting rods. The push out and retraction of the linear electric actuator lead to the action of three connecting rods, thereby realizing the pitching motion of the solar panel. The advantages of this are: firstly, the push-out stroke of the linear electric actuator is greatly shortened, and the linear electric actuator only needs to be pushed out or retracted for a small distance to realize a relatively large pitching motion of the battery panel through the linkage mechanism. Secondly, because the linear electric actuator is placed horizontally on the rotating panel, the stability of the system is increased, and the problem of possible interference between the linear electric actuator and other parts is reduced when the system is rotating.
机构水平方向的旋转运动通过如下方式来实现:系统旋转面板上的重量全部由推力轴承来承担,推力轴承的上轴圈固定在旋转面板中,下轴圈固定在轴承支撑板中,轴承支撑板固定在两个支撑角铁上,支撑角铁安装在下支撑板上,负责机构水平旋转运动的直流电机通过 The horizontal rotation of the mechanism is realized in the following way: the weight on the rotating panel of the system is entirely borne by the thrust bearing, the upper shaft ring of the thrust bearing is fixed in the rotating panel, the lower shaft ring is fixed in the bearing support plate, and the bearing support plate It is fixed on two supporting angle irons, and the supporting angle irons are installed on the lower supporting plate, and the DC motor responsible for the horizontal rotation of the mechanism passes through
NMRV蜗轮蜗杆减速箱将其动力传递给竖直方向的传动轴,传动轴上端和旋转面板通过螺栓相连,下端穿过中间带孔的下支撑板,并在传动轴的下端安装有螺母用于防止整个装置在竖直方向的窜动和倾倒。 The NMRV worm gear reducer transmits its power to the vertical transmission shaft. The upper end of the transmission shaft is connected with the rotating panel by bolts, and the lower end passes through the lower support plate with a hole in the middle, and a nut is installed at the lower end of the transmission shaft to prevent The entire device moves and topples in the vertical direction.
根据上述发明构思,本发明采用下述技术方案: According to above-mentioned inventive concept, the present invention adopts following technical scheme:
一种连杆式双轴太阳能跟踪机构,包括支撑圆管,太阳能电池板和水平旋转面板,其特征在于:所述支撑圆管固定在由铸铁方管构成的十字底座上,在十字底座下分别装有脚轮,使得整个机构便于移动;支撑圆管的顶端通过一个转动机构连接所述水平面板,所述太阳能电池板通过一个俯仰机构安装于水平旋转面板上,从而实现太阳电池板的转动和改变仰角。 A link-type dual-axis solar tracking mechanism, including a supporting circular tube, a solar panel and a horizontal rotating panel, characterized in that: the supporting circular tube is fixed on a cross base made of cast iron square tubes, and under the cross base, respectively Equipped with casters, the whole mechanism is easy to move; the top of the support tube is connected to the horizontal panel through a rotating mechanism, and the solar panel is installed on the horizontal rotating panel through a pitching mechanism, so as to realize the rotation and change of the solar panel elevation angle.
所述俯仰机构的结构是:一个直线电动推杆固定于水平旋转面板上,一根连杆甲的一端和太阳能电池板铰接,另一端和一根连杆乙连杆及一根连杆丙的一端铰接于一点(A),连杆乙的另一端铰接于一块固定在水平旋转面板上的角铁上,连杆丙的另一端和所述直线电动推杆铰接;当直线电动推杆的伸缩端伸出时,会带动连杆丙、连杆甲和连杆乙动作,使得太阳能电池板的仰角变大,反之,当直线电动推杆的伸缩端缩进时,会使得太阳能电池板的仰角变小。 The structure of the pitch mechanism is: a linear electric push rod is fixed on the horizontal rotating panel, one end of a connecting rod A is hinged with the solar panel, the other end is connected with a connecting rod B connecting rod and a connecting rod C One end is hinged at one point (A), the other end of the connecting rod B is hinged on an angle iron fixed on the horizontal rotating panel, and the other end of the connecting rod C is hinged with the linear electric actuator; when the linear electric actuator stretches When the telescopic end of the linear electric actuator is retracted, it will drive the action of connecting rod C, connecting rod A and connecting rod B, so that the elevation angle of the solar panel will become larger. Conversely, when the telescopic end of the linear electric actuator is retracted, the elevation angle of the solar panel will get smaller.
所述转动机构的结构是:一个直流电机经过一个蜗轮蜗杆减速箱的减速,将动力传递给一根垂直传动轴,该垂直传动轴的上端通过螺栓和旋转面板相连,垂直传动轴的下端从一块固定在支撑圆管顶端的下支撑板中间的孔伸出,并在垂直传动轴的下端加工有螺纹,并装有螺母,目的在于防止整个装置在竖直方向的窜动,一个推力轴承的上轴承圈固定在水平旋转面板中,而下轴承圈固定在一块轴承支撑板中,该轴承支撑板固定在两个支撑角铁上,支撑角铁固定在下支撑板上,整个机构的重量,全部通过推力轴承最终传递给四个脚轮,垂直传动轴不受轴向力,因此直流电机可以较容易的带动整个转台的旋转。 The structure of the rotating mechanism is: a DC motor is decelerated by a worm gear box, and the power is transmitted to a vertical transmission shaft. The hole in the middle of the lower support plate fixed on the top of the support tube protrudes, and the lower end of the vertical transmission shaft is threaded and equipped with nuts, the purpose is to prevent the entire device from moving in the vertical direction, and the upper end of a thrust bearing The bearing ring is fixed in the horizontal rotating panel, and the lower bearing ring is fixed in a bearing support plate, and the bearing support plate is fixed on two support angle irons, and the support angle iron is fixed on the lower support plate. The weight of the whole mechanism, all through The thrust bearing is finally transmitted to the four casters, and the vertical transmission shaft is not subject to axial force, so the DC motor can easily drive the rotation of the entire turntable.
本发明与现有技术相比较,具有如下显而易见的突出实质性特点和显著技术进步: Compared with the prior art, the present invention has the following obvious outstanding substantive features and significant technological progress:
本发明竖直方向的重量全部通过推力轴承并最终传递给了四个脚轮,竖直传动轴不受轴向力,保证了减速箱的寿命;本发明的直流电机驱动转动机构,直线电动推杆驱动俯仰机构,使太阳能电池板实现转动和改变仰角,跟踪阳光。本发明结构紧凑,成本低廉。 The weight in the vertical direction of the present invention is all passed through the thrust bearing and finally transmitted to the four casters. The vertical transmission shaft is not subject to axial force, which ensures the life of the reduction box; the DC motor of the present invention drives the rotating mechanism, and the linear electric push rod Drive the pitch mechanism to make the solar panel rotate and change the elevation angle to track the sunlight. The invention has compact structure and low cost.
附图说明 Description of drawings
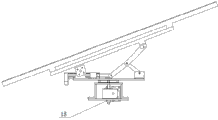
图1为本发明的结构示意图。 Fig. 1 is the structural representation of the present invention.
图2为图1的正视图。 Figure 2 is a front view of Figure 1.
图3为图1的局部视图。 Figure 3 is a partial view of Figure 1.
具体实施方式 Detailed ways
下面结合附图对本发明的优选实施例作详细说明。 Preferred embodiments of the present invention will be described in detail below in conjunction with the accompanying drawings.
实施例一: Embodiment one:
参见图1~图3,本连杆式双轴太阳能跟踪机构,包括支撑圆管(3),太阳能电池板(9)和水平旋转面板(7),其特征在于:所述支撑圆管(3)固定在由铸铁方管构成的十字底座(2)上,在十字底座(2)下分别装有脚轮(1),使得整个机构便于移动;支撑圆管(3)的顶端通过一个转动机构连接所述水平面板(7),所述太阳能电池板(9)通过一个俯仰机构安装于水平旋转面板(7)上,从而实现太阳电池板(9)的转动和改变仰角。 Referring to Figures 1 to 3, this connecting rod type biaxial solar tracking mechanism includes a supporting circular tube (3), a solar panel (9) and a horizontal rotating panel (7), and is characterized in that: the supporting circular tube (3 ) is fixed on the cross base (2) made of cast iron square tube, and casters (1) are installed under the cross base (2), making the whole mechanism easy to move; the top of the supporting round tube (3) is connected by a rotating mechanism The horizontal panel (7) and the solar battery panel (9) are installed on the horizontal rotating panel (7) through a pitch mechanism, so as to realize the rotation and change of the elevation angle of the solar battery panel (9).
实施例二: Embodiment two:
本实施例与实施例一基本相同,其特别之处是: This embodiment is basically the same as Embodiment 1, and its special features are:
所述俯仰机构的结构是:一个直线电动推杆(8)固定于水平旋转面板(7)上,一根连杆甲(10)的一端和太阳能电池板(9)铰接,另一端和一根连杆乙(11)连杆及一根连杆丙(13)的一端铰接于一点(A),连杆乙(11)的另一端铰接于一块固定在水平旋转面板上的角铁(12)上,连杆丙(13)的另一端和所述直线电动推杆(8)铰接;当直线电动推杆(8)的伸缩端伸出时,会带动连杆丙(13)、连杆甲(10)和连杆乙(11)动作,使得太阳能电池板(9)的仰角变大,反之,当直线电动推杆(8)的伸缩端缩进时,会使得太阳能电池板(9)的仰角变小。 The structure of the pitching mechanism is: a linear electric push rod (8) is fixed on the horizontal rotating panel (7), one end of a connecting rod armor (10) is hinged to the solar panel (9), and the other end is connected to a One end of connecting rod B (11) and one connecting rod C (13) are hinged at one point (A), and the other end of connecting rod B (11) is hinged at an angle iron (12) fixed on a horizontal rotating panel The other end of the connecting rod C (13) is hinged with the linear electric push rod (8); when the telescopic end of the linear electric push rod (8) stretches out, it will drive the connecting rod C (13), connecting rod A (10) and connecting rod B (11) act to make the elevation angle of the solar panel (9) larger, on the contrary, when the telescopic end of the linear electric push rod (8) retracts, it will make the solar panel (9) The elevation angle becomes smaller.
所述转动机构的结构是:一个直流电机(17)经过一个蜗轮蜗杆减速箱(4)的减速,将动力传递给一根垂直传动轴(15),该垂直传动轴(15)的上端通过螺栓和旋转面板(7)相连,垂直传动轴(15)的下端从一块固定在支撑圆管(3)顶端的下支撑板(16)中间的孔伸出,并在垂直传动轴(15)的下端加工有螺纹,并装有螺母(18),目的在于防止整个装置在竖直方向的窜动,一个推力轴承(14)的上轴承圈固定在水平旋转面板(7)中,而下轴承圈固定在一块轴承支撑板(6)中,该轴承支撑板(6)固定在两个支撑角铁(5)上,支撑角铁(5)固定在下支撑板(16)上,整个机构的重量,全部通过推力轴承(14)最终传递给四个脚轮(1),垂直传动轴(15)不受轴向力,因此直流电机(17)可以较容易的带动整个转台的旋转。 The structure of the rotating mechanism is: a DC motor (17) is decelerated by a worm gear box (4), and the power is transmitted to a vertical transmission shaft (15), and the upper end of the vertical transmission shaft (15) is passed through a bolt Connected with the rotating panel (7), the lower end of the vertical transmission shaft (15) protrudes from a hole in the middle of the lower support plate (16) fixed on the top of the support tube (3), and the lower end of the vertical transmission shaft (15) It is threaded and equipped with nuts (18), the purpose of which is to prevent the entire device from moving in the vertical direction. The upper bearing ring of a thrust bearing (14) is fixed in the horizontal rotation panel (7), while the lower bearing ring is fixed In a bearing support plate (6), the bearing support plate (6) is fixed on two support angle irons (5), and the support angle iron (5) is fixed on the lower support plate (16), the weight of the whole mechanism, all The thrust bearing (14) is finally transmitted to the four casters (1), and the vertical transmission shaft (15) is free from axial force, so the DC motor (17) can easily drive the rotation of the entire turntable.
实施例三: Embodiment three:
如图1~图3所示,一种连杆式太阳能双轴跟踪装置。包括支撑圆管(3),太阳能电池板(9),水平旋转面板(7),支撑圆管(3)固定在由铸铁方管构成的十字底座(2)上,在铸铁方管下分别装有脚轮(1),使得整个机构便于移动。直线电动推杆(8)水平固定于旋转面板(7)上,当直线电动推杆(8)的伸缩端伸出时,会带动连杆(13),连杆(10),连杆(11)的动作,使得电池板(9)的仰角变大,反之,当直线电动推杆(8)的伸缩端缩进时,会使得电池板(9)的仰角变小,从而实现太阳能电池板(9)的俯仰运动,用于高度角方向的追踪。直流电机(17)经过NMRV蜗轮蜗杆减速箱(4)的减速,将动力传递给垂直传动轴(15),垂直传动轴(15)的上端通过螺栓和旋转面板(7)相连,垂直传动轴(15)的下端从下支撑板(16)中间的孔伸出,并在垂直传动轴(15)的下端加工有螺纹,且装有螺母(18),目的在于防止整个装置在竖直方向的窜动。推力轴承(14)的上轴承圈固定在旋转面板(7)中,下轴承圈固定在轴承支撑板(6)中,轴承支撑板(6)固定在两个支撑角铁(5)上,支撑角铁(5)固定在下支撑板(16)上,整个系统在竖直方向的上的重量,全部通过推力轴承(14)最终传递给四个脚轮(1),直流电机(17)的转动带动整个旋转面板(7)的转动,实现系统在方位角方向对阳光的跟踪。 As shown in Figures 1 to 3, a link-type solar dual-axis tracking device. Including support round tube (3), solar panel (9), horizontal rotating panel (7), support round tube (3) is fixed on the cross base (2) made of cast iron square tube, installed under the cast iron square tube respectively There are casters (1) to make the whole mechanism easy to move. The linear electric push rod (8) is horizontally fixed on the rotating panel (7). When the telescopic end of the linear electric push rod (8) stretches out, it will drive the connecting rod (13), connecting rod (10), connecting rod (11 ) action makes the elevation angle of the solar panel (9) larger, on the contrary, when the telescopic end of the linear electric push rod (8) retracts, the elevation angle of the solar panel (9) becomes smaller, thereby realizing the solar panel ( 9) The pitch motion is used for tracking in the direction of altitude angle. The DC motor (17) is decelerated by the NMRV worm gearbox (4), and transmits the power to the vertical transmission shaft (15). The upper end of the vertical transmission shaft (15) is connected with the rotating panel (7) through bolts, and the vertical transmission shaft ( The lower end of 15) protrudes from the hole in the middle of the lower support plate (16), and the lower end of the vertical transmission shaft (15) is threaded, and a nut (18) is installed to prevent the whole device from moving in the vertical direction. move. The upper bearing ring of the thrust bearing (14) is fixed in the rotating panel (7), the lower bearing ring is fixed in the bearing support plate (6), and the bearing support plate (6) is fixed on two support angle irons (5), supporting The angle iron (5) is fixed on the lower support plate (16), and the weight of the entire system in the vertical direction is finally transmitted to the four casters (1) through the thrust bearing (14), and the rotation of the DC motor (17) drives The rotation of the entire rotating panel (7) enables the system to track sunlight in the azimuth direction. the
Claims (3)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310225114.1A CN103345260B (en) | 2013-06-07 | 2013-06-07 | Link-type double-shaft solar follower |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310225114.1A CN103345260B (en) | 2013-06-07 | 2013-06-07 | Link-type double-shaft solar follower |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN103345260A true CN103345260A (en) | 2013-10-09 |
| CN103345260B CN103345260B (en) | 2016-01-13 |
Family
ID=49280063
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201310225114.1A Expired - Fee Related CN103345260B (en) | 2013-06-07 | 2013-06-07 | Link-type double-shaft solar follower |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN103345260B (en) |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103914085A (en) * | 2014-04-14 | 2014-07-09 | 华北电力大学 | Device and method for achieving sunlight tracking through bar shadow image |
| CN104776609A (en) * | 2015-04-15 | 2015-07-15 | 宁波大智机械科技有限公司 | Solar device |
| CN107251415A (en) * | 2015-01-30 | 2017-10-13 | 纳博特斯克有限公司 | Board driving mchanism and heliostat |
| CN109698669A (en) * | 2017-10-20 | 2019-04-30 | Sener工程系统私人控股公司 | Azimuth and elevation angle rotating mechanism for sun follower |
| CN110572117A (en) * | 2019-10-16 | 2019-12-13 | 正信光电科技股份有限公司 | A full-angle adjustment bracket for photovoltaic modules |
| CN112785827A (en) * | 2019-11-06 | 2021-05-11 | 沈阳新松机器人自动化股份有限公司 | Antenna angle control system and method based on network communication technology |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2011134004A1 (en) * | 2010-04-27 | 2011-11-03 | Upton Ecoforlife Solar Trackers Pty. Ltd. | Solar tracking system |
| CN102541072A (en) * | 2010-12-09 | 2012-07-04 | 西安中科麦特电子技术设备有限公司 | Sunlight double-axis tracking device |
| CN102968125A (en) * | 2012-11-06 | 2013-03-13 | 刘建中 | Sunlight dual-shaft tracking support |
| CN202838764U (en) * | 2012-07-05 | 2013-03-27 | 浙江天煌科技实业有限公司 | Photovoltaic power generation system for simulating and tracking sun trajectory |
-
2013
- 2013-06-07 CN CN201310225114.1A patent/CN103345260B/en not_active Expired - Fee Related
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2011134004A1 (en) * | 2010-04-27 | 2011-11-03 | Upton Ecoforlife Solar Trackers Pty. Ltd. | Solar tracking system |
| CN102541072A (en) * | 2010-12-09 | 2012-07-04 | 西安中科麦特电子技术设备有限公司 | Sunlight double-axis tracking device |
| CN202838764U (en) * | 2012-07-05 | 2013-03-27 | 浙江天煌科技实业有限公司 | Photovoltaic power generation system for simulating and tracking sun trajectory |
| CN102968125A (en) * | 2012-11-06 | 2013-03-13 | 刘建中 | Sunlight dual-shaft tracking support |
Cited By (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103914085A (en) * | 2014-04-14 | 2014-07-09 | 华北电力大学 | Device and method for achieving sunlight tracking through bar shadow image |
| CN103914085B (en) * | 2014-04-14 | 2016-04-20 | 华北电力大学 | A kind of apparatus and method utilizing flagpole shadow paths picture to realize sun light tracking |
| CN107251415A (en) * | 2015-01-30 | 2017-10-13 | 纳博特斯克有限公司 | Board driving mchanism and heliostat |
| CN104776609A (en) * | 2015-04-15 | 2015-07-15 | 宁波大智机械科技有限公司 | Solar device |
| CN104776609B (en) * | 2015-04-15 | 2017-01-18 | 宁波大智机械科技有限公司 | Solar device |
| CN109698669A (en) * | 2017-10-20 | 2019-04-30 | Sener工程系统私人控股公司 | Azimuth and elevation angle rotating mechanism for sun follower |
| CN110572117A (en) * | 2019-10-16 | 2019-12-13 | 正信光电科技股份有限公司 | A full-angle adjustment bracket for photovoltaic modules |
| CN112785827A (en) * | 2019-11-06 | 2021-05-11 | 沈阳新松机器人自动化股份有限公司 | Antenna angle control system and method based on network communication technology |
| CN112785827B (en) * | 2019-11-06 | 2023-09-19 | 沈阳新松机器人自动化股份有限公司 | Antenna angle control system and method based on network communication technology |
Also Published As
| Publication number | Publication date |
|---|---|
| CN103345260B (en) | 2016-01-13 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102589157B (en) | Disc-type solar light condensation device | |
| CN201319572Y (en) | Photovoltaic generating unit automatically tracking the sun | |
| CN103345260B (en) | Link-type double-shaft solar follower | |
| CN201717808U (en) | Sunflower type sun tracking device | |
| CN201629700U (en) | Main-frame in shape like Chinese character 'yue' tracker mounting for double-axis automatic-tracking solar power generating device | |
| CN102195527B (en) | Electric push rod-controlled photovoltaic generating set for automatically tracking sun with double shafts | |
| CN101923355B (en) | Rotary luffing sun tracker | |
| CN201557059U (en) | Automatic spiral lifting sun-tracking device | |
| CN206180944U (en) | Two poles support automatic solar tracking controlling means | |
| KR101398292B1 (en) | Tracking Type floating Photovoltaic system | |
| CN107465384A (en) | A kind of photovoltaic module of angle rotatable | |
| CN208459859U (en) | A kind of large-sized photovoltaic square matrix numerical control rail mounted device day by day | |
| CN102158132B (en) | All-dome hydraulic-drive solar tracking system | |
| CN106990793A (en) | A kind of new flat uniaxial tracking bracket | |
| CN202257284U (en) | Novel sun autotracking mechanical device | |
| CN103956966A (en) | Solar-cell power generation double-shaft tracking support device | |
| CN103426944A (en) | A solar panel support system | |
| CN211653505U (en) | Rear-mounted rear-drive single-shaft photovoltaic tracker of rotary speed reducer | |
| CN203133616U (en) | Multiple-spindle connecting rod type sun chasing structure | |
| CN203689163U (en) | Two-dimensional solar tracking mechanism | |
| CN106685324B (en) | A kind of photovoltaic device | |
| CN201141710Y (en) | Slewing support device for array solar photothermal power generation collector | |
| CN203734600U (en) | Solar cell generation dual-shaft tracking support device | |
| CN206422728U (en) | Wind-solar complementary integrated power generation structure | |
| CN105577091A (en) | Connecting rod automatic sun tracking device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20170414 Address after: 201206 Shanghai, Pudong New Area Jin Hai Road, building 1000, building 3, No. 21 Patentee after: Shanghai is recognized Kexin Energy Technology Co. Ltd Address before: 200444 Baoshan District Road, Shanghai, No. 99 Patentee before: Shanghai University |
|
| TR01 | Transfer of patent right | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20160113 Termination date: 20210607 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |