Four station valve body automatic processing machine tools
Technical field
The present invention relates to a kind of lathe, be specifically related to a kind of four station valve body automatic processing machine tools.
Background technology
Valve is the requisite easy consumption product of modern industry, agricultural, chemical industry and daily life, and its valve body is mainly used universal machine tools to process.Because the application of universal machine tools is wide, must process not smart, and product quality affected by operator's human factor larger, stability can not well be guaranteed.
In addition, a workpiece needs many lathes jointly to complete, as needs adopt respectively hole enlarging machine tool, tapper etc.Chinese invention patent application 200910019846.9 discloses a kind of double-ended semiautomatic tapping machine of connecting, is exactly the special purpose machine tool for machining screw.The method of the common processing of this many lathes, needs a plurality of parts to have enough to meet the need, and causes production efficiency low.Along with market increases the demand of rotary body workpiece, the mode of production of obvious this poor efficiency has no longer adapted to the large-scale production of valve.
Summary of the invention
Technical problem to be solved by this invention is to provide a kind of four station valve body automatic processing machine tools, and it can integrate material loading, bore hole, tapping, discharging.
For solving the problems of the technologies described above, the technical solution of the present invention's four station valve body automatic processing machine tools is:
Comprise rotary disk 13, rotary disk 13 connects gear 43 by clutch 44; Under the effect of hydraulic cylinder, tooth bar side-to-side movement, drives gear 43 rotations that are engaged with, and gear 43 drives rotary disk 13 rotations by clutch 44, realizes the conversion of station; On the circumference of described rotary disk 13, be evenly equipped with four stations, the first station be positioned at rotary disk 13 directly over, the second station is positioned at the front-left of rotary disk 13, the 3rd station be positioned at rotary disk 13 under, the 4th station is positioned at the front-right of rotary disk 13; Workpiece to be processed is mounted location on the first station, carries out bore hole on the second station, on the 3rd station, carries out tapping, on the 4th station, takes off, and completes material loading, bore hole, tapping, four operations of blanking.
On described each station, be respectively arranged with one group of lever clamping mechanism, described lever clamping mechanism comprises lever 30, and lever 30 is fixed on the cylindrical of rotary disk 13 by lever pole 29; The Partner Connection Release nut 11 of lever 30, discharges nut 11 by spring guide pillar 32 linking springs 33; Spring 33 is fixedly installed on the cylindrical of rotary disk 13; The drive end of lever 30 connects top board 16, and top board 16 connects lower platen 28 by guide rod 27; Lower platen 28 is fixedly installed on the main bearing 12 of rotary disk 13.
The described lever clamping mechanism in the first station and the 4th station is respectively arranged with Pneumatic Pressure mechanism; Pneumatic Pressure mechanism comprises unloads carrier gas cylinder 8, unloads carrier gas cylinder 8 and by connecting rod 9, connects the top board 16 of described lever clamping mechanism.
The described lever clamping mechanism in the second station and the 3rd station is respectively arranged with pneumatically loading mechanism; Pneumatically loading mechanism comprises and adds carrier gas cylinder 39, and the piston that adds carrier gas cylinder 39 connects load bars 36 by connecting rod 38, and load bar 36 connects the top board 16 of described lever clamping mechanism; By adding carrier gas cylinder 39, drive connecting rod 38, make 36 pairs of top board 16 application of forces of load bar, complete the loading in process.
The both sides, front and back of described rotary disk 13 second stations are respectively arranged with a set of bore hole mechanism; Bore hole mechanism comprises bore hole main shaft 18, is provided with boring cutter 45 on bore hole main shaft 18; Bore hole main shaft 18 connects bore hole axis feeding driving mechanism and bore hole main shaft rotary drive mechanism; Described bore hole axis feeding driving mechanism comprises feeding cylinder 20, and one end of described bore hole main shaft 18 connects the piston of feeding cylinder 20; Feeding cylinder 20 promotes boring cutter 45 and realizes front and back feed motion; Described bore hole main shaft rotary drive mechanism comprises rotary drive motor 2, and described bore hole main shaft 18 connects rotary drive motor 2 by belt wheel 19; Rotary drive motor 2 drives bore hole main shaft 18, realizes the rotation of boring cutter 45.
One end of described bore hole main shaft 18 connects double-direction thrust ball bearing 55, and double-direction thrust ball bearing 55 is arranged in double-direction thrust ball bearing case 54, and double-direction thrust ball bearing case 54 connects the piston of feeding cylinder 20 by adapter sleeve capping 56.
On described bore hole main shaft 18, fixed cover is provided with axle sleeve 50, and axle sleeve 50 is connected with sleeve 48 by bearing 49; Boring cutter 45 is installed on sleeve 48; One end of sleeve 48 connects axle head capping 51, and axle head capping 51 connects described bore hole main shaft 18.
The both sides, front and back of described rotary disk 13 the 3rd station are respectively arranged with a set of tapper mechanism; Tapper mechanism comprises tapping transmission case driving shaft 24, on tapping transmission case driving shaft 24, is provided with screw tap; One end of tapping transmission case driving shaft 24 connects screw tap advance and retreat control cylinder 23, and screw tap advance and retreat control cylinder 23, for controlling the front and back feed motion of tapping transmission case driving shaft 24, makes the screw tap contact on tapping transmission case driving shaft 24 or leaves work piece; On tapping transmission case driving shaft 24, be arranged with rotating control wheel 60, rotating control wheel 60 connects respectively the passive angular wheel 58,62 of forward and backward by forward and reverse transmission cone friction drum 59,61; The passive angular wheel 58,62 of rotating is meshed with initiative taper generating gear 63, and initiative taper generating gear 63 connects belt wheel 65 by drive sprocket axle 64; By belt wheel 65 transmitting torques, make drive sprocket axle 64 work, drive sprocket axle 64 drives 63 rotations of initiative taper generating gear, initiative taper generating gear 63 and passive angular wheel 58,62 engagements of rotating, drive passive angular wheel 58,62 rotations of rotating, the passive angular wheel 58,62 of rotating drives 60 rotations of rotating control wheel by forward and reverse transmission cone friction drum 59,61, thereby drives 24 rotatings of tapping transmission case driving shaft; Rotating control wheel 60 connects double-direction thrust ball bearing 79, double-direction thrust ball bearing 79 is arranged in double-direction thrust ball bearing casing 78, double-direction thrust ball bearing casing 78 is by supporter 66 connecting ball head seats 67, in ball cup 67, be provided with bulb 68, bulb 68 connects screw tap rotating control cylinder 22 by connector 70; By screw tap rotating control cylinder 22, regulate double-direction thrust ball bearing 79, rotating control wheel 60 is contacted with forward transmission cone friction drum 59 or reverse drive cone friction drum 61, the passive angular wheel 58 of tapping transmission case driving shaft 24 and forward or the passive angular wheel 62 that reverses are connected, to control the direction of rotation of tapping transmission case driving shaft 24.
One end of described tapping transmission case driving shaft 24 is connected with double-direction thrust ball bearing case 74 by connecting rod 75, is provided with double-direction thrust ball bearing 73 in double-direction thrust ball bearing case 74; Double-direction thrust ball bearing case 74 connects the piston of screw tap advance and retreat control cylinder 23 by adapter sleeve cap seal 71.
On the end face of described rotary disk 13, be provided with four station locating holes 34; One side of rotary disk 13 is provided with positioning cylinder 41; When the station locating hole 34 that positioning cylinder 41 is aimed in below, can realize accurate location.
The technique effect that the present invention can reach is:
The rotation of the present invention by rotary disk and location and then complete material loading, bore hole, tapping, four operations of blanking, can overcome the shortcoming that a workpiece need to be processed on a plurality of lathes, greatly improve working (machining) efficiency, save labor cost, and ensure product quality stability.
Slew gear of the present invention can be realized rotation and send part, only needs workpiece to be positioned over fixture, just can deliver to processing stations by Automatic-clamping, realizes automation processing.
The present invention, in bore hole, tapping, can pick and place new work piece, greatly improves working (machining) efficiency.
Accompanying drawing explanation
Below in conjunction with the drawings and specific embodiments, the present invention is further detailed explanation:
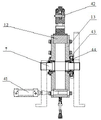
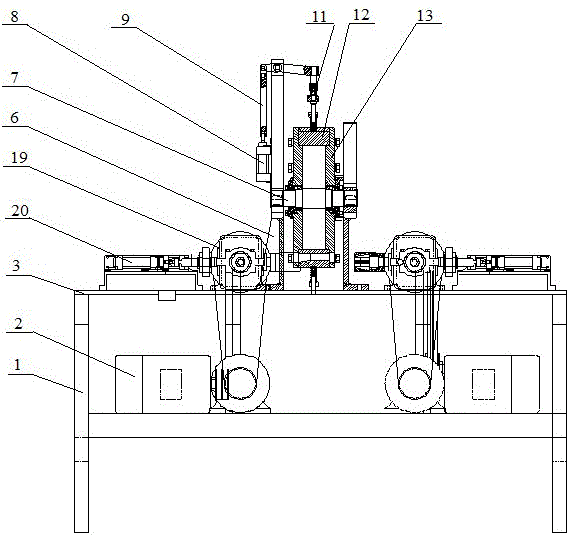
Fig. 1 is the structural representation of the present invention's four station valve body automatic processing machine tools;
Fig. 2 is the top view of Fig. 1;
Fig. 3 is the structural representation of slew gear of the present invention;
Fig. 4 is the A-A cutaway view in Fig. 3;
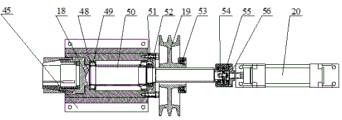
Fig. 5 is the structural representation of bore hole of the present invention mechanism;
Fig. 6 is the partial schematic diagram of tapper mechanism of the present invention;
Fig. 7 is another partial schematic diagram of tapper mechanism of the present invention.
Description of reference numerals in figure:
1 is frame, and 2 is rotary drive motor,
3 is support, 6 gripper shoes,
7 is main shaft,
8 for unloading carrier gas cylinder, and 9 is connecting rod,
11 for discharging nut, and 12 is the main bearing of rotary disk,
13 is rotary disk, and 16 is top board,
18 is bore hole main shaft, and 19 is belt wheel,
20 is feeding cylinder, and 22 is screw tap rotating control cylinder,
23 is screw tap advance and retreat control cylinder, and 24 is tapping transmission case driving shaft,
27 is guide rod, and 28 is lower platen,
29 is lever pole, and 30 is lever,
31 is material loading workpiece discharge mechanism, and 32 is spring guide pillar,
33 is spring, and 34 is station locating hole,
35 is blanking workpiece discharge mechanism, and 36 is load bar,
37 for supporting fixture, and 38 is connecting rod,
39 for adding carrier gas cylinder, and 40 is air cylinder support,
41 is positioning cylinder, and 42 is pivot pin,
43 is gear, and 44 is overrunning cluth,
45 is boring cutter, and 48 is sleeve,
49 is bearing, and 50 is axle sleeve,
51 is axle head capping, and 52 is nut,
53 is Pulley shaft bearing, and 54 is double-direction thrust ball bearing case,
55 is double-direction thrust ball bearing, and 56 is adapter sleeve capping,
58 is the passive angular wheel of forward, and 59 is forward transmission cone friction drum,
60 is rotating control wheel, and 61 is forward transmission cone friction drum,
62 is the passive angular wheel of reversion, and 63 is initiative taper generating gear,
64 is drive sprocket axle, and 65 is belt wheel.
The specific embodiment
As shown in Figure 1 and Figure 2, the present invention's four station valve body automatic processing machine tools, comprise slew gear, support; Slew gear is arranged on support;
Support comprises frame 1 and support 3; Support 3 supports by frame 1;
As shown in Figure 3, Figure 4, slew gear comprises rotary disk 13, and rotary disk 13 is arranged on main shaft 7, and rotary disk 13 is connected with overrunning cluth 44 by bolt, and the cylindrical of overrunning cluth 44 coordinates with gear 43 by needle roller; Overrunning cluth 44 is also arranged on main shaft 7;
Under the effect of hydraulic cylinder, tooth bar side-to-side movement, drives gear 43 rotations that are engaged with, and gear 43 drives rotary disk 13 rotations by overrunning cluth 44, realizes the conversion of station;
On the circumference of rotary disk 13, be evenly equipped with four groups of lever clamping mechanisms; 90 °, every two groups of lever clamping mechanism intervals, two groups of lever clamping mechanisms top in rotary disk 13 wherein, the below of other two groups of lever clamping mechanisms in rotary disk 13;
Lever clamping mechanism comprises lever 30, and lever 30 is fixed on the cylindrical of rotary disk 13 by lever pole 29; The Partner Connection Release nut 11 of lever 30, discharges nut 11 by spring guide pillar 32 linking springs 33; Spring 33 is fixedly installed on the cylindrical of rotary disk 13;
The drive end of lever 30 connects top board 16, and top board 16 connects lower platen 28 by guide rod 27; Lower platen 28 is fixedly installed on the main bearing 12 of rotary disk 13; Top board 16 is connected with lever 30 by pivot pin 42;
Two groups of lever clamping mechanisms in rotary disk 13 tops, wherein the release nut 11 of one group of lever clamping mechanism be positioned at rotary disk 13 directly over, i.e. the first station; The release nut 11 of another group lever clamping mechanism is positioned at the front-right of rotary disk 13, i.e. the 4th station;
Two groups of lever clamping mechanisms in rotary disk 13 tops are respectively arranged with Pneumatic Pressure mechanism; Pneumatic Pressure mechanism comprises unloads carrier gas cylinder 8, unloads carrier gas cylinder 8 and by connecting rod 9, connects the top board 16 of lever clamping mechanism;
When workpiece is during in the 4th station, by unloading carrier gas cylinder 8, promote connecting rods 9, make to lift on the top board 16 of lever 30 drive ends, the Partner of lever 30 presses down, thereby to discharging nut 11 pressurizations, spring 33 compressions, workpiece blanking device 35 is taken workpiece away, completes the unloading of workpiece;
When in the first station, workpiece feeding device 31 is sent into workpiece, unloads carrier gas cylinder 8 backhauls, spring 33 is in returning the state of stretching, and spring 33 promotes spring guide pillar 32 and rises, and drives top board 16 to press down by lever 30, complete the fixing of workpiece, thereby realize material loading, discharging.
In two groups of lever clamping mechanisms of rotary disk 13 belows, wherein the release nut 11 of one group of lever clamping mechanism is positioned at the front-left of rotary disk 13, i.e. the second station; Release nut 11 of another group lever clamping mechanism be positioned at rotary disk 13 under, i.e. the 3rd station;
Two groups of lever clamping mechanisms in rotary disk 13 belows are respectively arranged with pneumatically loading mechanism; Pneumatically loading mechanism comprises and adds carrier gas cylinder 39, and the piston that adds carrier gas cylinder 39 connects load bars 36 by connecting rod 38, and load bar 36 connects the top board 16 of lever clamping mechanisms;
Load bar 36 is movably set in and supports in fixture 37, supports the bottom surface that fixture 37 is fixedly installed on support 3; Supporting fixture 37 plays a supportive role for load bar 36;
Adding carrier gas cylinder 39 is fixed in frame 1 by air cylinder support 40;
By adding carrier gas cylinder 39, drive connecting rod 38, make 36 pairs of top board 16 application of forces of load bar, complete the loading in process.
The both sides, front and back of rotary disk 13 second stations are respectively arranged with a set of bore hole mechanism; As shown in Figure 5, bore hole mechanism comprises bore hole main shaft 18, is provided with boring cutter 45 on bore hole main shaft 18; Bore hole main shaft 18 connects bore hole axis feeding driving mechanism and bore hole main shaft rotary drive mechanism;
Bore hole axis feeding driving mechanism comprises feeding cylinder 20, one end of bore hole main shaft 18 is connected with double-direction thrust ball bearing 55 by screw, double-direction thrust ball bearing 55 is arranged in double-direction thrust ball bearing case 54, and double-direction thrust ball bearing case 54 connects the piston of feeding cylinder 20 by adapter sleeve capping 56; Feeding cylinder 20 promotes boring cutter 45 and seesaws;
On bore hole main shaft 18, fixed cover is provided with axle sleeve 50, and axle sleeve 50 is connected with sleeve 48 by bearing 49; Boring cutter 45 is installed on sleeve 48; One end of sleeve 48 is bolted axle head capping 51, and axle head capping 51 connects bore hole main shaft 18 by nut 52; Feeding cylinder 20 promotes 18 motions of bore hole main shaft, and bore hole main shaft 18 drives boring cutter 45 towards equidirectional motion by axle sleeve 50, bearing 49, sleeve 48;
Bore hole main shaft rotary drive mechanism comprises rotary drive motor, and the middle part of bore hole main shaft 18 connects rotary drive motor 2 by belt wheel 19, and rotary drive motor 2 drives 18 rotations of bore hole main shaft by belt wheel 19; On belt wheel 19, be provided with the Pulley shaft bearing 53 that deep groove ball bearing is housed; Bore hole main shaft 18 is by spline joint belt wheel 19.
The both sides, front and back of rotary disk 13 the 3rd station are respectively arranged with a set of tapper mechanism; As shown in Figure 6, tapper mechanism comprises tapping transmission case driving shaft 24, on tapping transmission case driving shaft 24, is provided with screw tap; One end of tapping transmission case driving shaft 24 is connected with double-direction thrust ball bearing case 74 by connecting rod 75, is provided with double-direction thrust ball bearing 73 in double-direction thrust ball bearing case 74; Double-direction thrust ball bearing case 74 connects the piston of screw tap advance and retreat control cylinder 23 by adapter sleeve cap seal 71; Screw tap advance and retreat control cylinder 23, for controlling the front and back feed motion of tapping transmission case driving shaft 24, makes the screw tap contact on tapping transmission case driving shaft 24 or leaves work piece.
On tapping transmission case driving shaft 24, be arranged with rotating control wheel 60, tapping transmission case driving shaft 24 is by spline joint rotating control wheel 60; As shown in Figure 7, rotating control wheel 60 connects respectively the passive angular wheel 58,62 of forward and backward by forward and reverse transmission cone friction drum 59,61; The passive angular wheel 58,62 of rotating is meshed with initiative taper generating gear 63, and initiative taper generating gear 63 connects belt wheel 65 by drive sprocket axle 64;
By belt wheel 65 transmitting torques, make drive sprocket axle 64 work, drive sprocket axle 64 drives 63 rotations of initiative taper generating gear, initiative taper generating gear 63 and passive angular wheel 58,62 engagements of rotating, drive passive angular wheel 58,62 rotations of rotating, the passive angular wheel 58,62 of rotating drives 60 rotations of rotating control wheel by forward and reverse transmission cone friction drum 59,61, thereby drives 24 rotatings of tapping transmission case driving shaft.
Rotating control wheel 60 connects double-direction thrust ball bearing 79 by nut 76, double-direction thrust ball bearing 79 is arranged in double-direction thrust ball bearing casing 78, double-direction thrust ball bearing casing 78 is by supporter 66 connecting ball head seats 67, in ball cup 67, be movably set with bulb 68, bulb 68 connects screw tap rotating control cylinder 22 by connector 70;
By screw tap rotating control cylinder 22, regulate double-direction thrust ball bearing 79, rotating control wheel 60 is contacted with forward transmission cone friction drum 59 or reverse drive cone friction drum 61, the passive angular wheel 58 of tapping transmission case driving shaft 24 and forward or the passive angular wheel 62 that reverses are connected, to control the direction of rotation of tapping transmission case driving shaft 24;
When rotating control wheel 60 contacts with forward transmission cone friction drum 59, tapping transmission case driving shaft 24 is connected with the passive angular wheel 58 of forward, and tapping transmission case driving shaft 24 forwards are carried out tapping; When rotating control wheel 60 contacts with reverse drive cone friction drum 61, tapping transmission case driving shaft 24 is connected with the passive angular wheel 62 of reversion, and 24 reversions of tapping transmission case driving shaft, make screw tap exit workpiece.
On the end face of rotary disk 13, be provided with four station locating holes 34; One side of rotary disk 13 is provided with positioning cylinder 41; When the station locating hole 34 that positioning cylinder 41 is aimed in below, can realize accurate location.
Operation principle of the present invention is as follows:
Rotate back to rotating disk 13, workpiece to be processed is arranged on the lever clamping mechanism in the first station; Again rotate back to rotating disk 13, make workpiece arrive the second station, to workpiece bore; Rotate back to for the third time rotating disk 13, make workpiece arrive the 3rd station, to work-piece tapping; Rotate back to rotating disk 13 the 4th time, make workpiece arrive the 4th station, take off workpiece, according to this cyclic process.