CN102434301B - Speed control method for electronic fuel injection automobile - Google Patents
Speed control method for electronic fuel injection automobile Download PDFInfo
- Publication number
- CN102434301B CN102434301B CN201110339572.9A CN201110339572A CN102434301B CN 102434301 B CN102434301 B CN 102434301B CN 201110339572 A CN201110339572 A CN 201110339572A CN 102434301 B CN102434301 B CN 102434301B
- Authority
- CN
- China
- Prior art keywords
- fuel injection
- speed
- engine
- automobile
- oil
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 239000000446 fuel Substances 0.000 title claims abstract description 96
- 238000002347 injection Methods 0.000 title claims abstract description 88
- 239000007924 injection Substances 0.000 title claims abstract description 88
- 238000000034 method Methods 0.000 title claims abstract description 26
- 230000001133 acceleration Effects 0.000 claims abstract description 25
- 239000003921 oil Substances 0.000 claims description 47
- 238000010304 firing Methods 0.000 claims description 30
- 239000010727 cylinder oil Substances 0.000 claims description 12
- 238000010586 diagram Methods 0.000 description 5
- 238000013459 approach Methods 0.000 description 2
- 238000005516 engineering process Methods 0.000 description 2
- 230000007613 environmental effect Effects 0.000 description 2
- 230000009977 dual effect Effects 0.000 description 1
- 238000011084 recovery Methods 0.000 description 1
- 230000007704 transition Effects 0.000 description 1
Images


Landscapes
- Control Of Vehicle Engines Or Engines For Specific Uses (AREA)
- Electrical Control Of Air Or Fuel Supplied To Internal-Combustion Engine (AREA)
Abstract
The invention discloses an automobile speed control method for an electronic fuel injection automobile, which can calculate automobile accelerated speed based on automobile speed signals, achieve current objective automobile speed according to current work condition, obtain a differential value by using the current automobile speed to subtract the current objective automobile speed, and calculate a special fuel injection mode threshold value according to current automobile acceleration speed. When the differential value is larger than or equal to the special fuel injection mode threshold value and the differential value is minus, number of times of continuous fuel injection sequence in fuel injection fuel cut sequence of each cylinder increases with enlargement of the absolute value of the differential value, and the continuous fuel injection sequence is separated by one fuel cut. When the differential value is zero, the fuel injection fuel cut sequence of each cylinder is in normal fuel injection mode. When the differential value is positive, number of times of continuous fuel cut sequence in fuel injection fuel cut sequence of each cylinder increases with enlargement of the differential value, and the continuous fuel cut sequence is separated by one fuel injection. The automobile speed control method for the electronic fuel injection automobile can effectively limit automobile of the electronic fuel injection automobile with a single cylinder engine or a multiple cylinder engine, and the automobile speed is small in fluctuation.
Description
Technical field
The present invention relates to engine technology, particularly a kind of automobile speed control method for electronic fuel injection automobile.
Background technique
Electric jet vehicle uses the electronic fuel injection controlling system of multi-point injection on motor, electronic fuel injection controlling system is take a control unit of engine (ECU) as control centre, utilization is arranged on the various sensors on motor different parts, record the various running parameters of motor, according to the control program of setting in control unit of engine (ECU), by controlling oil sprayer control fuel injection quantity, controlling method is flexible, can realize the accurate control of engine air-fuel ratio, make motor under various operating modes, can obtain the mixed gas of optium concentration.
Vehicle-speed limit is the important guarantee of vehicle safety, all there is different requirements in different countries and application, all the more so for non-road bike, for example U.S. EPA (U.S Environmental Protection Agency, Environmental Protection Agency) has the demand of speed limit 40Km/h for four-wheel agriculture motorcycle; In reverse gear position, or when 4 wheel driven lock position, for the purpose of safety, also need strictly to limit Vehicle Speed for vehicle.
The method of common restricted speed, one is to increase mechanical device, restriction throttle body valve block aperture, thereby limiting engine power, but this method is at vehicle during in different gear, or while having different demand according to operating mode, cannot accomplish to limit the speed of a motor vehicle of different demands, therefore generally only limit to meet the demand of Power Limitation, another kind is by detecting speed of a motor vehicle sensor signal, in the time that the speed of a motor vehicle arrives the target limit speed of a motor vehicle, the limit value that electronic fuel injection controlling system exceedes according to the speed of a motor vehicle is controlled respectively one or more cylinder oil-breaks, below the speed of a motor vehicle drops to target vehicle speed time, recover each oil supply cylinder, thereby reach the object of restricted speed, but this oil-break method, cannot accurately control the fuel feeding of a concrete cylinder, for single-cylinder engine, oil-break means whole power cuts, when recovery, whole power recovers, can cause power output discontinuous, speed of a motor vehicle fluctuation is very large, driving demand cannot meet the speed of a motor vehicle control time.
Summary of the invention
The technical problem to be solved in the present invention is to provide a kind of automobile speed control method for electronic fuel injection automobile, can effectively limit the speed of a motor vehicle of single cylinder and multicylinder engine electric jet vehicle, and speed of a motor vehicle fluctuation is little.
For solving the problems of the technologies described above, automobile speed control method for electronic fuel injection automobile of the present invention, comprises the following steps:
One. Offered target speedometer in storage, described target vehicle speed table, for demarcating the target vehicle speed under different operating modes;
Two. control unit of engine gathers working condition signal, vehicle speed signal;
Three. control unit of engine calculates current vehicle acceleration according to the vehicle speed signal gathering, and according to the current working signal gathering, looks into target vehicle speed table and obtain the current goal speed of a motor vehicle, then current vehicle speed is deducted to the current goal speed of a motor vehicle and obtains difference;
Four. control unit of engine, according to the special fuel injection mode threshold value function of current vehicle acceleration and setting, calculates special fuel injection mode threshold value;
Described special fuel injection mode threshold value function, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration;
Five. if difference is more than or equal to special fuel injection mode threshold value, carries out step 6, otherwise carries out step 7;
Six. control unit of engine is according to difference, by following oil spout oil-break sequence, the each cylinder oil spout of control engine:
When difference is when negative, in the oil spout oil-break sequence of each cylinder, the number of times of oil spout sequence increases along with the increase of the absolute value of difference continuously, continuously between oil spout sequence by an oil-break interval;
In the time that difference is zero, the oil spout oil-break sequence of each cylinder is normal fuel injection mode;
When difference is timing, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil-break sequence increases along with the increase of difference, continuously between oil-break sequence by an injection interval;
Seven. control unit of engine is by the each cylinder oil spout of normal fuel injection mode control engine.
Under normal fuel injection mode, the oil spout oil-break sequence of the each cylinder of the each cylinder oil spout of motor can be that an oil spout is with an oil-break space.
Described operating mode can comprise range state, drive pattern state, in described target vehicle speed table, range state while being reverse gear corresponding target vehicle speed be demarcated as the speed of a motor vehicle that reverse gear need to limit, range state while being forward gears corresponding target vehicle speed be demarcated as the speed of a motor vehicle that forward gears need to limit, drive pattern while being 4 wheel driven lockup state corresponding target vehicle speed be demarcated as the speed of a motor vehicle that 4 wheel driven locking need to limit.
Described special fuel injection mode threshold value function, can be that special fuel injection mode threshold value reduces along with the increase of vehicle acceleration, and when vehicle acceleration be timing, special fuel injection mode threshold value is for negative.
In step 2, control unit of engine can also gather engine rotational speed signal;
In step 6, control unit of engine can also calculate present engine rotating speed according to the engine speed gathering and increase gradient, engine speed increases gradient, a rear engine speed that is identical acquisition time interval deducts the poor of last engine speed, then according to the firing angle increment control algorithm function of setting, calculate firing angle increment and carry out lower pass-filter;
Described firing angle increment control algorithm function, firing angle increment is along with engine speed increases the increase of gradient and increases, and in the time that engine speed increases gradient and is positive number, firing angle increment is also positive number;
If it is positive number that present engine rotating speed increases gradient, control unit of engine deducts firing angle increment as each cylinder actual ignition angle with former basic firing angle, the each cylinder igniting of control engine;
In step 7, control unit of engine, by lighting a fire by the each cylinder of normal fired mode control engine, under normal fired mode, is also using former basic firing angle as each cylinder actual ignition angle.
Automobile speed control method for electronic fuel injection automobile of the present invention, when the speed of a motor vehicle approaches target vehicle speed, can pre-decelerating, approach lenitively target vehicle speed, the speed of a motor vehicle is only carried out small fluctuation near remaining on target vehicle speed always, vehicle is advanced stably, thereby realize the dual requirements of speed of a motor vehicle control and driving, be specially adapted to adopt the single cylinder petrol engine motorcycle of mechanical type air throttle body.
Accompanying drawing explanation
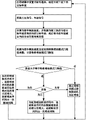
Fig. 1 is automobile speed control method for electronic fuel injection automobile first embodiment's schematic diagram of the present invention;
Fig. 2 is oil spout and the fuel cut-off control law curve schematic diagram of automobile speed control method for electronic fuel injection automobile one mode of execution of the present invention;
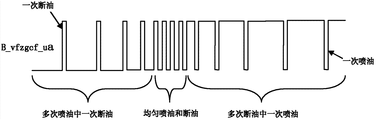
Fig. 3 is oil spout and the fuel cut-off control sequence schematic diagram of automobile speed control method for electronic fuel injection automobile one mode of execution of the present invention;
Fig. 4 is automobile speed control method for electronic fuel injection automobile second embodiment's schematic diagram of the present invention;
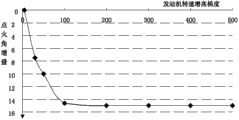
Fig. 5 is the firing angle increment control algorithm function schematic diagram of automobile speed control method for electronic fuel injection automobile one mode of execution of the present invention.
Embodiment
Below in conjunction with accompanying drawing, the technological scheme in the application is carried out to clear, complete description, obviously, described embodiment is a part of embodiment of the application, rather than whole embodiments.Based on the embodiment in the application, all other embodiments that those of ordinary skills obtain under the prerequisite of not making creative work, belong to the scope that the application protects.
Automobile speed control method for electronic fuel injection automobile of the present invention, the first embodiment as shown in Figure 1, comprises the following steps:
One. Offered target speedometer in storage;
Described target vehicle speed table, for demarcating the target vehicle speed under different operating modes, each operating mode corresponds respectively to corresponding target vehicle speed; For example, described operating mode comprises range state, drive pattern state, in described target vehicle speed table, range state while being reverse gear corresponding target vehicle speed be demarcated as the speed of a motor vehicle that reverse gear need to limit, range state while being forward gears corresponding target vehicle speed be demarcated as the speed of a motor vehicle that forward gears need to limit, drive pattern while being 4 wheel driven lockup state corresponding target vehicle speed be demarcated as the speed of a motor vehicle that 4 wheel driven locking need to limit;
Two. control unit of engine (ECU) gathers the vehicle speed signal of each working condition signal, vehicle speed sensor;
Three. control unit of engine (ECU) calculates current vehicle acceleration according to the vehicle speed signal gathering, and according to the current working signal gathering, look into target vehicle speed table and obtain the current goal speed of a motor vehicle, then current vehicle speed is deducted to the current goal speed of a motor vehicle and obtain difference dvs_w_ua, when difference dvs_w_ua is when negative, illustrate that current vehicle speed is lower than the current goal speed of a motor vehicle, when difference dvs_w_ua is timing, illustrate that current vehicle speed is higher than the current goal speed of a motor vehicle;
Four. control unit of engine (ECU), according to the special fuel injection mode threshold value function of current vehicle acceleration and setting, calculates special fuel injection mode threshold value;
Described special fuel injection mode threshold value function, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration; Preferably, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration, and when vehicle acceleration be timing, special fuel injection mode threshold value is for negative;
Five. if difference dvs_w_ua is more than or equal to special fuel injection mode threshold value, carries out step 6, otherwise carries out step 7;
Six. control unit of engine (ECU) is according to difference dvs_w_ua, by following oil spout oil-break sequence, the each cylinder oil spout of control engine: when difference dvs_w_ua is when negative, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil spout sequence increases along with the increase of the absolute value of difference dvs_w_ua, continuously between oil spout sequence by an oil-break interval; In the time that difference dvs_w_ua is zero, the oil spout oil-break sequence of each cylinder is normal fuel injection mode, and, in the oil spout oil-break sequence of each cylinder, an oil spout is with an oil-break space; When difference dvs_w_ua is timing, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil-break sequence increases along with the increase of difference dvs_w_ua, continuously between oil-break sequence by an injection interval.Concrete oil spout and fuel cut-off control law curve are as shown in Figure 2, in figure, abscissa is difference dvs_w_ua, y coordinate is the number of times of continuous oil spout or continuous oil-break, actual oil spout and fuel cut-off control sequence are as shown in Figure 3, in figure, B_vfzgcf_ua is for allowing fuel cut-off control flag bit, and B_vfzgcf_ua equals 1 o'clock oil-break; B_vfzgcf_ua equals oil spout in 0 o'clock;
Then enter step 2;
Seven. control unit of engine (ECU) is by the each cylinder oil spout of normal fuel injection mode control engine, and under normal fuel injection mode, the oil spout oil-break sequence of the each cylinder of the each cylinder oil spout of motor is that an oil spout is with an oil-break space;
Then enter step 2.
Automobile speed control method for electronic fuel injection automobile the second embodiment of the present invention as shown in Figure 4, comprises the following steps:
One. Offered target speedometer in storage;
Described target vehicle speed table, for demarcating the target vehicle speed under different operating modes, each operating mode corresponds respectively to corresponding target vehicle speed;
Two. control unit of engine (ECU) gathers each working condition signal, vehicle speed signal, engine rotational speed signal;
Three. control unit of engine (ECU) calculates current vehicle acceleration according to the vehicle speed signal gathering, and according to the current working signal gathering, look into target vehicle speed table and obtain the current goal speed of a motor vehicle, then current vehicle speed is deducted to the current goal speed of a motor vehicle and obtain difference dvs_w_ua;
Four. control unit of engine (ECU), according to the special fuel injection mode threshold value function of current vehicle acceleration and setting, calculates special fuel injection mode threshold value;
Described special fuel injection mode threshold value function, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration; Preferably, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration, and when vehicle acceleration be timing, special fuel injection mode threshold value is for negative;
Five. if difference dvs_w_ua is more than or equal to special fuel injection mode threshold value, carries out step 6, otherwise carries out step 7;
Six. control unit of engine (ECU) is according to difference dvs_w_ua, by following oil spout oil-break sequence, the each cylinder oil spout of control engine: when difference dvs_w_ua is when negative, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil spout sequence increases along with the increase of the absolute value of difference dvs_w_ua, continuously between oil spout sequence by an oil-break interval; In the time that difference dvs_w_ua is zero, the oil spout oil-break sequence of each cylinder is normal fuel injection mode, and, in the oil spout oil-break sequence of each cylinder, an oil spout is with an oil-break space; When difference dvs_w_ua is timing, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil-break sequence increases along with the increase of difference dvs_w_ua, continuously between oil-break sequence by an injection interval;
Control unit of engine (ECU) increases gradient according to the engine speed calculating present engine rotating speed gathering, and (engine speed increases gradient, a rear engine speed that is identical acquisition time interval deducts the poor of last engine speed), then according to the firing angle increment control algorithm function of setting, calculate firing angle increment and carry out lower pass-filter, as shown in Figure 5, described firing angle increment control algorithm function, firing angle increment is along with engine speed increases the increase of gradient and increases, and in the time that engine speed increases gradient and is positive number, firing angle increment is also positive number,
If it is positive number that present engine rotating speed increases gradient, control unit of engine (ECU) deducts firing angle increment as each cylinder actual ignition angle with former basic firing angle, the each cylinder igniting of control engine;
Then enter step 2;
Seven. control unit of engine (ECU) is by the each cylinder oil spout of normal fuel injection mode control engine, and under normal fuel injection mode, the oil spout oil-break sequence of the each cylinder of the each cylinder oil spout of motor is that an oil spout is with an oil-break space;
Control unit of engine (ECU), by the each cylinder igniting of normal fired mode control engine, under normal fired mode, is using former basic firing angle as each cylinder actual ignition angle;
Then enter step 2.
Automobile speed control method for electronic fuel injection automobile of the present invention, in actual travel process, when driver opens the throttle, vehicle is accelerated, current vehicle acceleration is greater than 0, control unit of engine (ECU) is according to current vehicle speed and current vehicle acceleration, determine special fuel injection mode threshold value, and further determine whether to enter special fuel injection mode according to the operating mode such as current vehicle speed and range state, as enter special fuel injection mode and before vehicle reaches curb-top speed, control oil spout oil-break sequence, make vehicle gently to curb-top speed transition and be stabilized near highest speed, when driver reduces throttle, reduce the speed of a motor vehicle, current vehicle acceleration is less than 0, control unit of engine (ECU) is according to current vehicle speed and current vehicle acceleration, determine special fuel injection mode threshold value, and further determine whether to exit special fuel injection mode according to the operating mode such as current vehicle speed and range state, as exit special fuel injection mode, enter normal oil spout control mode, thereby oil-break and oil spout to the every work cycle of motor are controlled in real time.Simultaneously, in the time entering special fuel injection mode, control unit of engine (ECU) increases the size of gradient according to engine speed, firing angle is carried out to dynamic increment control, the size of this increment is the function that engine speed increases gradient, by the control of firing angle increment control algorithm function, engine speed increase is faster, increment is larger, engine speed increase is slower, increment is less, increment reduces after lower pass-filter on former basic firing angle, igniting to the every work cycle of motor is controlled in real time, make in the time that engine speed significantly rises, actual ignition angle is less than former basic firing angle, in the time that the speed of a motor vehicle is controlled in stablizing, the variation of engine speed is slower, increment is also relatively little on firing angle impact, thereby Engine torque is carried out to dynamic auxiliary control, control torque output reposefully.
Claims (4)
1. an automobile speed control method for electronic fuel injection automobile, is characterized in that, comprises the following steps:
One. Offered target speedometer in storage, described target vehicle speed table, for demarcating the target vehicle speed under different operating modes;
Two. control unit of engine gathers working condition signal, vehicle speed signal;
Three. control unit of engine calculates current vehicle acceleration according to the vehicle speed signal gathering, and according to the current working signal gathering, looks into target vehicle speed table and obtain the current goal speed of a motor vehicle, then current vehicle speed is deducted to the current goal speed of a motor vehicle and obtains difference;
Four. control unit of engine, according to the special fuel injection mode threshold value function of current vehicle acceleration and setting, calculates special fuel injection mode threshold value;
Described special fuel injection mode threshold value function, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration;
Five. if difference is more than or equal to special fuel injection mode threshold value, carries out step 6, otherwise carries out step 7;
Six. control unit of engine is according to difference, by following oil spout oil-break sequence, the each cylinder oil spout of control engine:
When difference is when negative, in the oil spout oil-break sequence of each cylinder, the number of times of oil spout sequence increases along with the increase of the absolute value of difference continuously, continuously between oil spout sequence by an oil-break interval;
In the time that difference is zero, the oil spout oil-break sequence of each cylinder is normal fuel injection mode;
When difference is timing, in the oil spout oil-break sequence of each cylinder, continuously the number of times of oil-break sequence increases along with the increase of difference, continuously between oil-break sequence by an injection interval;
Seven. control unit of engine is by the each cylinder oil spout of normal fuel injection mode control engine;
Under normal fuel injection mode, the oil spout oil-break sequence of the each cylinder of the each cylinder oil spout of motor is that an oil spout is with an oil-break space.
2. automobile speed control method for electronic fuel injection automobile according to claim 1, it is characterized in that, described operating mode comprises range state, drive pattern state, in described target vehicle speed table, range state while being reverse gear corresponding target vehicle speed be demarcated as the speed of a motor vehicle that reverse gear need to limit, range state while being forward gears corresponding target vehicle speed be demarcated as the speed of a motor vehicle that forward gears need to limit, drive pattern while being 4 wheel driven lockup state corresponding target vehicle speed be demarcated as the speed of a motor vehicle that 4 wheel driven locking need to limit.
3. automobile speed control method for electronic fuel injection automobile according to claim 1, it is characterized in that, described special fuel injection mode threshold value function, special fuel injection mode threshold value reduces along with the increase of vehicle acceleration, and when vehicle acceleration is timing, special fuel injection mode threshold value is for negative.
4. according to the automobile speed control method for electronic fuel injection automobile described in claim 1 to 4 any one, it is characterized in that,
In step 2, control unit of engine also gathers engine rotational speed signal;
In step 6, control unit of engine also calculates present engine rotating speed according to the engine speed gathering and increases gradient, engine speed increases gradient, a rear engine speed that is identical acquisition time interval deducts the poor of last engine speed, then according to the firing angle increment control algorithm function of setting, calculate firing angle increment and carry out lower pass-filter;
Described firing angle increment control algorithm function, firing angle increment is along with engine speed increases the increase of gradient and increases, and in the time that engine speed increases gradient and is positive number, firing angle increment is also positive number;
If it is positive number that present engine rotating speed increases gradient, control unit of engine deducts firing angle increment as each cylinder actual ignition angle with former basic firing angle, the each cylinder igniting of control engine;
In step 7, control unit of engine, by the each cylinder igniting of normal fired mode control engine, under normal fired mode, is also using former basic firing angle as each cylinder actual ignition angle.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201110339572.9A CN102434301B (en) | 2011-11-01 | 2011-11-01 | Speed control method for electronic fuel injection automobile |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201110339572.9A CN102434301B (en) | 2011-11-01 | 2011-11-01 | Speed control method for electronic fuel injection automobile |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN102434301A CN102434301A (en) | 2012-05-02 |
| CN102434301B true CN102434301B (en) | 2014-05-14 |
Family
ID=45982597
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201110339572.9A Active CN102434301B (en) | 2011-11-01 | 2011-11-01 | Speed control method for electronic fuel injection automobile |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN102434301B (en) |
Families Citing this family (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN107061036B (en) * | 2017-01-25 | 2020-03-24 | 安徽江淮汽车集团股份有限公司 | Automobile deceleration fuel cut-off control method |
| CN110758416B (en) * | 2019-10-31 | 2020-11-10 | 北京易控智驾科技有限公司 | Control system and control method for gear limit of unmanned mine car |
| CN115217960B (en) * | 2022-01-05 | 2024-03-26 | 广州汽车集团股份有限公司 | Control method for power downshift and double-clutch transmission |
| CN115534995B (en) * | 2022-09-30 | 2025-09-19 | 嬴彻星创智能科技(上海)有限公司 | Automatic driving mode activatable state identification method and device |
| CN117627800A (en) * | 2023-12-11 | 2024-03-01 | 东风华神汽车有限公司 | A method, device and vehicle for eliminating jitter at vehicle speed limit points |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN1145159A (en) * | 1995-09-07 | 1997-03-19 | 久保田株式会社 | Speed control device of harvester |
| CN1173216A (en) * | 1994-12-27 | 1998-02-11 | 株式会社小松制作所 | Speed limiting device and method for work vehicle |
| US5819703A (en) * | 1996-06-28 | 1998-10-13 | Hewitt; John T. | Vehicle speed limiting system |
| CN101025123A (en) * | 2007-01-25 | 2007-08-29 | 重庆长安汽车股份有限公司 | Method for limiting speed of electrojet low-speed vehicle |
Family Cites Families (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH05225496A (en) * | 1992-02-10 | 1993-09-03 | Matsushita Electric Ind Co Ltd | Car speed management system |
-
2011
- 2011-11-01 CN CN201110339572.9A patent/CN102434301B/en active Active
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN1173216A (en) * | 1994-12-27 | 1998-02-11 | 株式会社小松制作所 | Speed limiting device and method for work vehicle |
| CN1145159A (en) * | 1995-09-07 | 1997-03-19 | 久保田株式会社 | Speed control device of harvester |
| US5819703A (en) * | 1996-06-28 | 1998-10-13 | Hewitt; John T. | Vehicle speed limiting system |
| CN101025123A (en) * | 2007-01-25 | 2007-08-29 | 重庆长安汽车股份有限公司 | Method for limiting speed of electrojet low-speed vehicle |
Also Published As
| Publication number | Publication date |
|---|---|
| CN102434301A (en) | 2012-05-02 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP2103796B1 (en) | Throttle opening control device, motorcycle, and method for producing control map | |
| CN102434301A (en) | Automobile speed control method for electronic fuel injection automobile | |
| US8290666B2 (en) | Method and system for controlling a vehicle engine during performance driving events | |
| US9581091B2 (en) | Control device for engine | |
| CN102628417A (en) | Starter control systems and methods for engine rockback | |
| CN104632431A (en) | Idling time-controlled flameout device for automobile | |
| CN105246747A (en) | Vehicle control device and control method | |
| JP2008121647A (en) | Vehicle control device | |
| US20080257323A1 (en) | Internal combustion engine system and vehicle, and ignition control method for internal combustion engine system | |
| CN204250042U (en) | A kind of manual-gear vehicle gearshift prompt system | |
| CN103993965B (en) | A kind of LPG/CNG Double-fuels EFI control method | |
| US9765704B2 (en) | Control device for engine | |
| US9650035B2 (en) | Control apparatus for hybrid vehicle | |
| CN101387235B (en) | Fuel injection controlling apparatus for internal combustion engine | |
| DE4143089C2 (en) | Ignition timing control system for internal combustion engines with slip control arrangement | |
| US4545349A (en) | Method for regulating intake air flow for internal combustion engines | |
| DE68908926T2 (en) | Slip control system for driven wheels of a motor vehicle. | |
| CN202578922U (en) | Device for eliminating gear shift impact in automobile | |
| CN103397961A (en) | Fuel supply system of all-terrain vehicle with two vehicle bodies | |
| US10294909B2 (en) | Engine control device | |
| JPS63154862A (en) | Electronic control device for internal combustion engine | |
| JPH0442535B2 (en) | ||
| JP2009298365A (en) | Power output device, vehicle having the same, and method of controlling power output device | |
| CN106640385B (en) | Dual fuel engine accelerates control method, control device, engine and vehicle | |
| CN204027581U (en) | For two-way crankshaft position sensor, firing system and the automobile of start and stop vehicle |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant |