CN102227071B - Manipulator clamping linking wire clamp special for high voltage electriferous work - Google Patents
Manipulator clamping linking wire clamp special for high voltage electriferous work Download PDFInfo
- Publication number
- CN102227071B CN102227071B CN 201110088113 CN201110088113A CN102227071B CN 102227071 B CN102227071 B CN 102227071B CN 201110088113 CN201110088113 CN 201110088113 CN 201110088113 A CN201110088113 A CN 201110088113A CN 102227071 B CN102227071 B CN 102227071B
- Authority
- CN
- China
- Prior art keywords
- block
- fixed support
- lower fixed
- manipulator
- support block
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Landscapes
- Electric Cable Installation (AREA)
Abstract
本发明涉及一种高压带电作业专用机械手夹持并股线夹。其中机械手夹持装置包括下置固定支承块,下置固定支承块设有机械手夹持位置,下置固定支承块设有两个相间隔的平行设置的半圆弧面,在下置固定支承块侧面则设有下固定支承侧面定位板,下固定支承侧面定位板上设有定位装置;所述引流线预固定压接装置为引流线预固定压块,引流线预固定压块与下置固定支承块紧固连接,引流线预固定压块还与所述定位装置配合;所述主导线固定压接装置为上置压块,上置压块通过紧固装置与下置固定支承块连接,上置压块也设有两个平行的半圆弧面,与下置固定支承块的两个半圆弧面相配合,同时在上置压块中部一侧设有开槽,引流线预固定压块安装在所述开槽内。

The invention relates to a special manipulator for high-voltage live-line work to hold a stranded wire clamp. Wherein the manipulator clamping device comprises a lower fixed support block, the lower fixed support block is provided with a manipulator clamping position, and the lower fixed support block is provided with two spaced parallel semicircular arc surfaces, and the lower fixed support block side The side positioning plate of the lower fixed support is provided, and the positioning device is arranged on the side positioning plate of the lower fixed support; The block is fastened and connected, and the pre-fixed pressure block of the drainage wire is also matched with the positioning device; the fixed and crimped device for the main wire is an upper pressure block, and the upper pressure block is connected with the lower fixed support block through the fastening device, and the upper The pressing block is also provided with two parallel semi-arc surfaces, which are matched with the two semi-arc surfaces of the lower fixed support block. At the same time, there is a slot on the middle side of the upper pressing block, and the drainage line pre-fixes the pressing block. installed in the slot.
Description
技术领域 technical field
本发明涉及一种导线专用连接金具,尤其涉及一种用于10Kv配电线路的高压带电作业专用机械手夹持并股线夹,可广泛适用于高压带电完成接线作业任务。 The invention relates to a special connection fitting for wires, in particular to a special manipulator for high-voltage live-line work for 10Kv power distribution lines to clamp and tie wire clamps, which can be widely used for high-voltage live-line work to complete wiring tasks.
背景技术 Background technique
高压线路的带电作业是电力设备测试、检修、改造的重要手段,它为提高供电可靠性,减少停电损失,保证电网安全做出了巨大贡献。高压带电作业机器人代替人工完成作业频率较高的带电断线、带电接线、带电更换跌落保险等作业任务,减轻作业人员的劳动强度,提高作业效率。夹持作业工具的机械手和操作者控制的主手是通过光纤完成数据和通讯信息传递与转换,使作业人员与高压电场完全隔离。采用机械手夹持并股线夹执行接线作业任务,避免操作者与带电导线直接接触,最大限度的保证作业人员的安全。而现有手工操作的并股线夹不适合机械手夹持作业,这就要求设计一种便于机械手夹持操作的新型并股线夹金具。 Live work on high-voltage lines is an important means of testing, repairing, and transforming power equipment. It has made great contributions to improving the reliability of power supply, reducing power failure losses, and ensuring the safety of the power grid. The high-voltage live working robot replaces manual work tasks such as live disconnection, live connection, and live replacement of drop insurance with high frequency of work, reducing the labor intensity of operators and improving work efficiency. The manipulator holding the work tool and the main hand controlled by the operator complete the transmission and conversion of data and communication information through optical fiber, so that the operator is completely isolated from the high-voltage electric field. The manipulator is used to clamp and strand the wire clamp to perform the wiring operation task, to avoid direct contact between the operator and the live wire, and to ensure the safety of the operator to the greatest extent. However, the existing manual-operated plied wire clamps are not suitable for manipulator clamping operations, which requires the design of a new type of plied strand clamp hardware that is convenient for manipulator clamping operations.
发明内容 Contents of the invention
本发明的目的就是为解决以上技术上的不足,设计一种高压带电作业专用机械手夹持并股线夹,它便于机械手夹持完成操作,为其他作业任务做好辅助准备。 The purpose of the present invention is to solve the above technical deficiencies, and to design a special manipulator for high-voltage live-line work to clamp and tie the strands, which is convenient for the manipulator to complete the operation and make auxiliary preparations for other tasks.
为实现上述目的,本发明采用以下技术方案: To achieve the above object, the present invention adopts the following technical solutions:
一种高压带电作业专用机械手夹持并股线夹,它包括引流线预固定压接装置、主导线固定压接装置和机械手夹持装置;其中,机械手夹持装置包括下置固定支承块,下置固定支承块设有机械手夹持位置,下置固定支承块设有两个相间隔的平行设置的半圆弧面,在下置固定支承块侧面则设有下固定支承侧面定位板,下固定支承侧面定位板上设有定位装置;所述引流线预固定压接装置为引流线预固定压块,引流线预固定压块与下置固定支承块紧固连接,引流线预固定压块还与所述定位装置配合;所述主导线固定压接装置为上置压块,上置压块通过紧固装置与下置固定支承块连接,上置压块也设有两个平行的半圆弧面,与下置固定支承块的两个半圆弧面相配合,同时在上置压块中部一侧设有开槽,引流线预固定压块安装在所述开槽内。 A special manipulator for high-voltage live work to hold and hold the strands, which includes a drain wire pre-fixed crimping device, a main wire fixed crimping device and a manipulator clamping device; wherein the manipulator clamping device includes a lower fixed support block, a lower The fixed support block is provided with a clamping position of the manipulator, and the fixed support block is provided with two spaced apart parallel semicircular arc surfaces, and the side positioning plate of the lower fixed support is provided on the side of the fixed support block. A positioning device is provided on the side positioning plate; the pre-fixed crimping device for the drainage line is a pre-fixed pressure block for the drainage line, which is tightly connected with the lower fixed support block, and the pre-fixed pressure block for the drainage line is also connected with the The positioning device cooperates; the main wire fixing crimping device is an upper pressing block, and the upper pressing block is connected with the lower fixed support block through a fastening device, and the upper pressing block is also provided with two parallel semicircular arcs The surface is matched with the two semi-arc surfaces of the lower fixed support block, and at the same time, a slot is provided on the middle side of the upper press block, and the pre-fixed press block of the drainage line is installed in the slot.
所述紧固装置为两个导向尼龙槽连接螺栓,导向尼龙槽连接螺栓通过圆弧配合面垫片贯穿上置压块和下置固定支承块,将两者紧固连接。 The fastening device is two guiding nylon groove connecting bolts, and the guiding nylon groove connecting bolts pass through the upper pressure block and the lower fixed support block through the circular arc mating surface gasket to fasten the two.
所述导向尼龙槽连接螺栓位于上置压块和下置固定支承块间的部分设有弹簧。 The part between the upper pressing block and the lower fixed support block of the guide nylon groove connecting bolt is provided with a spring.
所述引流线预固定压块通过引流线固定螺栓与下置固定支承块连接,引流线预固定压块与定位装置配合。 The pre-fixed pressing block of the drainage line is connected with the lower fixed support block through the fixing bolt of the drainage line, and the pre-fixed pressing block of the drainage line cooperates with the positioning device.
所述引流线固定螺栓与引流线预固定压块间设有弹簧垫圈和圆弧配合面垫片。 A spring washer and an arc mating surface gasket are arranged between the drainage wire fixing bolt and the drainage wire pre-fixed pressing block.
所述定位装置为配合定位槽,所述引流线预固定压块设有凸块与配合定位槽配合。 The positioning device is a matching positioning groove, and the pre-fixed pressure block of the drainage wire is provided with a protrusion to cooperate with the matching positioning groove.
所述机械手夹持位置两侧开有半圆弧形凸面。 There are semicircular convex surfaces on both sides of the clamping position of the manipulator.
本发明的高压带电作业专用机械手夹持并股线夹,它包括引流线预固定压接装置、主导线固定压接装置、机械手夹持装置等三部分构成。 The special-purpose manipulator for high-voltage live work of the present invention clamps the stranded wire clamp, which includes three parts: the pre-fixed and crimped device for the drain wire, the fixed and crimped device for the main wire, and the clamping device for the manipulator.
所述引流线预固定压接装置包括引流线预固定压块、下置固定支承块和引流线固定螺栓紧固连接。将引流线预先人工手动压紧在引流线预固定压块半圆弧面与下置固定支承块半圆弧面之间,用引流线固定螺栓紧固连接,加装弹簧垫圈起到螺栓防松作用。引流线预固定压块通过下固定支承侧面的配合定位槽完成定位安装。 The drainage wire pre-fixing and crimping device includes a drainage wire pre-fixing press block, a lower fixed support block and a drainage wire fixing bolt for fastening connection. Manually tighten the drainage line in advance between the semi-arc surface of the pre-fixed pressure block of the drainage line and the semi-arc surface of the lower fixed support block, fasten the connection with the fixing bolt of the drainage line, and install a spring washer to prevent the bolt from loosening effect. The pre-fixed pressure block of the drainage line is positioned and installed through the matching positioning groove on the side of the lower fixed support.
所述主导线固定压接装置包括上置压块、下置固定支承块和导向尼龙槽连接螺栓紧固连接。主导线由导向尼龙槽连接螺栓压紧在上置压块的半圆弧面和下置固定支承块的半圆弧面之间。下置固定支承块中间开有三个内螺纹通孔,与导向尼龙槽连接螺栓完成紧固导线连接。内嵌于下置固定支承块中间通孔内的弹簧将上置压块和下置固定支承块预先撑开,便于引流线和主导线的插入连接,上紧导向尼龙槽连接螺栓后,弹簧处于压紧状态。上置压块通过下固定支承侧面定位板的侧面配合完成定位安装。 The fixing and crimping device for the main wire includes an upper pressing block, a lower fixing support block and a guide nylon groove connecting bolts for fastening connection. The main wire is pressed between the semi-arc surface of the upper pressing block and the semi-arc surface of the lower fixed support block by the guide nylon groove connection bolt. There are three internal thread through holes in the middle of the lower fixed support block, which are connected with the guide nylon groove connecting bolts to complete the fastening wire connection. The spring embedded in the middle through hole of the lower fixed support block pre-stretches the upper pressure block and the lower fixed support block to facilitate the insertion and connection of the drainage wire and the main wire. After tightening the connecting bolts of the guide nylon groove, the spring is in the Compressed state. The upper pressing block completes the positioning and installation through the cooperation of the side of the lower fixed support side positioning plate.
所述机械手夹持装置由机械手夹持位置两侧开有半圆弧形凸面,便于机械手半圆弧形凹槽面配合夹持。 The gripping device of the manipulator is provided with a semi-arc-shaped convex surface on both sides of the gripping position of the manipulator, which is convenient for the manipulator to cooperate with the semi-arc-shaped groove surface.
本发明的有益效果是:适用于10Kv配电线路带电接线作业任务,采用机械手夹持并股线夹执行接线作业任务,由于机械手和操作者控制的主手是通过光纤完成数据和通讯信息传递与转换,从而避免操作者与带电导线直接接触,大幅度提高作业安全性。该并股线夹可适用于机械手方便快捷夹持、安装和拆卸,完成接线任务。 The beneficial effects of the present invention are: it is suitable for the live wiring operation task of 10Kv power distribution line, and the manipulator is used to clamp and tie the strand clamp to perform the wiring operation task, because the main hand controlled by the manipulator and the operator is to complete the data and communication information transmission and communication through optical fiber Conversion, so as to avoid direct contact between the operator and the live wire, greatly improving the safety of operation. The strand clamp is suitable for the manipulator to conveniently and quickly clamp, install and disassemble to complete the wiring task.
附图说明 Description of drawings
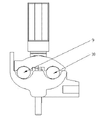
图1 为本发明立体结构示意图; Fig. 1 is the three-dimensional structure schematic diagram of the present invention;
图2 为本发明侧面图; Fig. 2 is a side view of the present invention;
图3 为本发明俯视图。 Fig. 3 is a top view of the present invention.
图中:1、导向尼龙槽连接螺栓,2、引流线固定螺栓,3、弹簧垫圈,4、圆弧配合面垫片,5、上置压块,6、弹簧,7、下置固定支承块,8、机械手夹持位置,9、引流线,10、主导线,11、下固定支承侧面定位板,12、配合定位槽,13、引流线预固定压块。 In the figure: 1. The connecting bolt of the guide nylon groove, 2. The fixing bolt of the drainage line, 3. The spring washer, 4. The gasket of the arc mating surface, 5. The upper pressing block, 6. The spring, 7. The lower fixed support block , 8, clamping position of manipulator, 9, drainage wire, 10, main wire, 11, lower fixed support side positioning plate, 12, matching positioning groove, 13, pre-fixed pressure block of drainage wire.
具体实施方式 Detailed ways
下面结合附图与实施例对本发明做进一步说明。 The present invention will be further described below in conjunction with the accompanying drawings and embodiments.
图1、图2、图3中,本发明主要由引流线预固定压接装置、主导线固定压接装置和机械手夹持装置等三部分构成。 In Fig. 1, Fig. 2, and Fig. 3, the present invention is mainly composed of three parts: a drain wire pre-fixed crimping device, a main lead wire fixing crimping device and a manipulator clamping device.
其中,机械手夹持装置包括下置固定支承块7,下置固定支承块7设有机械手夹持位置8,下置固定支承块7设有两个相间隔的平行设置的半圆弧面,在下置固定支承块7侧面则设有下固定支承侧面定位板11,下固定支承侧面定位板11上设有定位装置;
Wherein, the manipulator clamping device comprises a lower fixed support block 7, and the lower fixed support block 7 is provided with a manipulator clamping position 8, and the lower fixed support block 7 is provided with two spaced parallel semicircular arc surfaces, The fixed support block 7 side is provided with the lower fixed support
所述引流线预固定压接装置为引流线预固定压块13,引流线预固定压块13与下置固定支承块7紧固连接,引流线预固定压块13还与所述定位装置配合;
The drainage wire pre-fixed crimping device is a drainage wire pre-fixed
所述主导线固定压接装置为上置压块5,上置压块5通过紧固装置与下置固定支承块7连接,上置压块5也设有两个平行的半圆弧面,与下置固定支承块7的两个半圆弧面相配合,同时在上置压块5中部设有开槽,引流线预固定压块13安装在所述开槽内。
The fixed and crimping device for the main wire is an upper
所述紧固装置为两个导向尼龙槽连接螺栓1,导向尼龙槽连接螺栓1通过圆弧配合面垫片贯穿上置压块5和下置固定支承块7,将两者紧固连接。
The fastening device is two guiding nylon groove connecting bolts 1, and the guiding nylon groove connecting bolts 1 pass through the
所述导向尼龙槽连接螺栓1位于上置压块5和下置固定支承块7间的部分设有弹簧6。
A
所述引流线预固定压块13通过引流线固定螺栓2与下置固定支承块7连接,引流线预固定压块13与定位装置配合。
The drainage wire pre-fixed
所述引流线固定螺栓2与引流线预固定压块13间设有弹簧垫圈3、圆弧配合面垫片4。
A spring washer 3 and an arc mating surface gasket 4 are arranged between the drain wire fixing bolt 2 and the drain wire pre-fixed
所述定位装置为配合定位槽12,所述引流线预固定压块13设有凸块与配合定位槽12配合。
The positioning device is a
所述机械手夹持位置8两侧开有半圆弧形凸面。 The two sides of the clamping position 8 of the manipulator are provided with semicircular convex surfaces.
本发明的使用过程为: The use process of the present invention is:
引流线预固定压接装置:将引流线9通过引流线固定螺栓2预先压紧在引流线预固定压块13的半圆弧面和下置固定支承块7的半圆弧面之间。弹簧垫圈3起到引流线固定螺栓2防松作用,圆弧配合面垫片4与引流线预固定压块13上弧面配合,便于引流线固定螺栓2紧固连接。引流线预固定压块13通过配合定位槽12完成下固定支承侧面定位板11的定位安装。
Drainage wire pre-fixed crimping device: pre-press the drainage wire 9 between the semicircular surface of the drainage wire pre-fixed
主导线固定压接部分:主导线10由导向尼龙槽连接螺栓1压紧在上置压块5的半圆弧面和下置固定支承块7的半圆弧面之间。弹簧6将上置压块和下置固定支承块预先撑开,便于引流线9和主导线10的插入连接,上紧导向尼龙槽连接螺栓1后,弹簧6处于压紧状态。上置压块5通过下固定支承侧面定位板11的完成定位安装。
Main wire fixed crimping part: The
机械手夹持部分:机械手夹持位置8两侧开有半圆弧形凸面,便于机械手半圆弧形凹槽面配合夹持。 Clamping part of the manipulator: there are semicircular convex surfaces on both sides of the manipulator clamping position 8, which is convenient for the manipulator to cooperate with the semicircular arc groove surface.
Claims (6)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201110088113 CN102227071B (en) | 2011-04-08 | 2011-04-08 | Manipulator clamping linking wire clamp special for high voltage electriferous work |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201110088113 CN102227071B (en) | 2011-04-08 | 2011-04-08 | Manipulator clamping linking wire clamp special for high voltage electriferous work |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN102227071A CN102227071A (en) | 2011-10-26 |
| CN102227071B true CN102227071B (en) | 2013-05-29 |
Family
ID=44808030
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN 201110088113 Active CN102227071B (en) | 2011-04-08 | 2011-04-08 | Manipulator clamping linking wire clamp special for high voltage electriferous work |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN102227071B (en) |
Families Citing this family (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102545091B (en) * | 2012-01-19 | 2015-02-18 | 国家电网公司 | Charged disconnecting wire lead clamp device |
| CN102832569B (en) * | 2012-09-05 | 2015-08-26 | 国家电网公司 | Based on the distribution network live line work drainage system of remote pilot |
| CN103441404A (en) * | 2013-08-20 | 2013-12-11 | 昆山达功电子有限公司 | Welding clamp for copper wires |
| CN104682261A (en) * | 2013-12-02 | 2015-06-03 | 国家电网公司 | Live working manipulator for high-voltage power transmission line |
| CN107053188A (en) * | 2016-12-09 | 2017-08-18 | 南京理工大学 | A kind of hot line robot branch connects gage lap method |
| CN107895911A (en) * | 2017-12-04 | 2018-04-10 | 云南电网有限责任公司怒江供电局 | A kind of Special wire-clip for 20kV line live-line works |
| JP6777682B2 (en) * | 2018-04-27 | 2020-10-28 | ファナック株式会社 | A robot hand having a plurality of grips, and a method of handling a wire harness using the robot hand. |
| CN111525448B (en) * | 2020-05-07 | 2021-10-15 | 北京国电富通科技发展有限责任公司 | A kind of wire clip intelligent installation tool and its intelligent equipment |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR2311954A1 (en) * | 1975-05-23 | 1976-12-17 | Fischer Heinrich | Parallel bar shelving clamp - incorporates U-shaped body with clamp fixture grooves, extension piece fitted to free arm |
| CN1247392A (en) * | 1999-10-11 | 2000-03-15 | 罗志昭 | High-elasticity locking wire clamp with high current load for joining-up |
| CN2579059Y (en) * | 2002-11-01 | 2003-10-08 | 谢福永 | Light cable clamp |
| CN201312094Y (en) * | 2008-12-09 | 2009-09-16 | 唐洪良 | Trislot parallel groove clamp |
| CN201994604U (en) * | 2011-04-08 | 2011-09-28 | 山东电力研究院 | Special manipulator clamping and stranding wire holder for high-voltage live-wire work |
-
2011
- 2011-04-08 CN CN 201110088113 patent/CN102227071B/en active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR2311954A1 (en) * | 1975-05-23 | 1976-12-17 | Fischer Heinrich | Parallel bar shelving clamp - incorporates U-shaped body with clamp fixture grooves, extension piece fitted to free arm |
| CN1247392A (en) * | 1999-10-11 | 2000-03-15 | 罗志昭 | High-elasticity locking wire clamp with high current load for joining-up |
| CN2579059Y (en) * | 2002-11-01 | 2003-10-08 | 谢福永 | Light cable clamp |
| CN201312094Y (en) * | 2008-12-09 | 2009-09-16 | 唐洪良 | Trislot parallel groove clamp |
| CN201994604U (en) * | 2011-04-08 | 2011-09-28 | 山东电力研究院 | Special manipulator clamping and stranding wire holder for high-voltage live-wire work |
Non-Patent Citations (2)
| Title |
|---|
| 彭晋英,1.JBL系列绝缘并沟线夹烧损分析及改进措施.《电力学报》.2009,(第02期),第159-160页. * |
| 骆国平等,1.并沟线夹可靠性研究.《高压电器》.2000,(第01期),第31-34页. * |
Also Published As
| Publication number | Publication date |
|---|---|
| CN102227071A (en) | 2011-10-26 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102227071A (en) | Manipulator clamping linking wire clamp special for high voltage electriferous work | |
| CN103683104A (en) | A ratchet combination tool for live fastening and draining clip | |
| CN201994604U (en) | Special manipulator clamping and stranding wire holder for high-voltage live-wire work | |
| CN109980381A (en) | A kind of electric connecting armour clamp and its method | |
| CN102136692A (en) | Tool for replacing JB type parallel groove clamp on live line | |
| CN104795771B (en) | Piercing clamps for ground potential live working of insulated conductors | |
| CN202633832U (en) | Parallel bunched cable wire clamping device | |
| CN208015264U (en) | A kind of modified steel wire clamp | |
| CN210120247U (en) | Distribution lines live working wire fastener that continues | |
| CN202534977U (en) | V-shaped clamping apparatus for transposing double insulator strings of power transmission line | |
| CN202026029U (en) | Conducting wire splitting clamp | |
| CN102201650A (en) | Electrification on and off lead wire crimping working method and shunting clamp | |
| CN204577638U (en) | A kind of multiple wire holes inflection wire clamp | |
| CN204103345U (en) | A kind of novel conductors on quad bundled strain insulator string side of wire link plate clamping tool | |
| CN206834354U (en) | Special for powered Da Huo robots takes live wire folder | |
| CN205159908U (en) | Backup protection fixing -line device | |
| CN203813378U (en) | Wire clamp for power distribution lines | |
| CN105826725B (en) | It can be achieved to have a power failure and the powered 10kV circuit double-strand chain wire clamps being connected respectively and operating method | |
| CN102922455A (en) | Automatic clamping device | |
| CN221176666U (en) | Parallel groove clamp suitable for automatic operation of machine | |
| CN206211066U (en) | Push-press type binding clip with fixing hole | |
| CN205385267U (en) | Parallel groove clamp for power transmission and transformation | |
| CN206237101U (en) | Push-press type binding clip | |
| CN106785522B (en) | Push-press type binding clip with fixation hole | |
| CN203171466U (en) | Automatic clamping device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| ASS | Succession or assignment of patent right |
Owner name: SHANDONG LUNENG INTELLIGENT TECHNOLOGY CO., LTD. S Free format text: FORMER OWNER: SHANDONG LUNENG INTELLIGENT TECHNOLOGY CO., LTD. Effective date: 20130109 |
|
| C41 | Transfer of patent application or patent right or utility model | ||
| TA01 | Transfer of patent application right |
Effective date of registration: 20130109 Address after: 250002 Ji'nan City Central District, Shandong, No. 2 South Road, No. 500 Applicant after: Shandong Research Inst. of Electric Power Applicant after: Shandong Luneng Intelligent Technology Co., Ltd. Applicant after: State Grid Corporation of China Address before: 250002 Ji'nan City Central District, Shandong, No. 2 South Road, No. 500 Applicant before: Shandong Research Inst. of Electric Power Applicant before: Shandong Luneng Intelligent Technology Co., Ltd. |
|
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| CP01 | Change in the name or title of a patent holder | ||
| CP01 | Change in the name or title of a patent holder |
Address after: 250002 Ji'nan City Central District, Shandong, No. 2 South Road, No. 500 Co-patentee after: National Network Intelligent Technology Co., Ltd. Patentee after: Shandong Research Inst. of Electric Power Co-patentee after: State Grid Corporation of China Address before: 250002 Ji'nan City Central District, Shandong, No. 2 South Road, No. 500 Co-patentee before: Shandong Luneng Intelligent Technology Co., Ltd. Patentee before: Shandong Research Inst. of Electric Power Co-patentee before: State Grid Corporation of China |
|
| TR01 | Transfer of patent right | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20201029 Address after: 250101 Electric Power Intelligent Robot Production Project 101 in Jinan City, Shandong Province, South of Feiyue Avenue and East of No. 26 Road (ICT Industrial Park) Patentee after: National Network Intelligent Technology Co.,Ltd. Address before: 250002 Ji'nan City Central District, Shandong, No. 2 South Road, No. 500 Patentee before: Shandong Electric Power Research Institute Patentee before: National Network Intelligent Technology Co.,Ltd. Patentee before: STATE GRID CORPORATION OF CHINA |